Advertisement Supported by The Justice Department is planning to appeal, but the decision is likely to significantly delay its investigation into former President Donald J. Trump’s handling of government records. Send any friend a story As a subscriber, you have 10 gift articles to give each month. Anyone can read what you share. By Charlie Savage, Alan Feuer and Glenn Thrush WASHINGTON — A federal judge on Thursday rejected the Justice Department’s request to resume a key part of its inquiry into former President Donald J. Trump’s handling of sensitive government records and appointed an outside arbiter to review thousands of documents seized last month from his Florida residence. The judge, Aileen M. Cannon, declined to lift any part of an order she issued last week that barred the department from using the documents, including about 100 marked classified, in its investigation until the arbiter, known as a special master, had completed a review. In her 10-page decision, Judge Cannon appointed a special master suggested by the Trump legal team and agreed upon by the government: Raymond J. Dearie, a semiretired judge from the Federal District Court for the Eastern District of New York. Judge Dearie will now have the authority to sift through more than 11,000 records the F.B.I. carted away from Mr. Trump’s estate, Mar-a-Lago, on Aug. 8. The move was a blow to the Justice Department, almost certain to significantly delay its investigation into whether the former president unlawfully retained national defense records or obstructed repeated attempts by federal officials to retrieve them. The department had asked Judge Cannon to lift restrictions on its use of documents with classification markings and set a Thursday deadline for her to respond before it said it would ask an appeals court to intervene. The department is now planning to appeal the decision, and top officials were meeting to discuss the timing of their filing, according to a senior law enforcement official. Judge Cannon’s order was the latest turn in what has now become a protracted and politically fraught court battle over the trove of documents seized in the search of Mar-a-Lago. While Judge Cannon’s order was a victory for Mr. Trump and his legal team, she also made two significant concessions to the government. She said, for instance, that Judge Dearie should first look at the classified documents and “thereafter consider prompt adjustments to the court’s orders as necessary.” That raised the possibility that Judge Dearie might quickly clear the items and the F.B.I. would then regain unrestricted use of them in its criminal inquiry. In her order, Judge Cannon said the special master should try to finish his review by Nov. 30. Judge Cannon also clarified her temporary ban on the Justice Department’s investigation. While the department could not present the seized documents to a grand jury or ask witnesses about their contents, she said, the F.B.I. could continue to investigate “the movement and storage of seized materials, including documents marked as classified, without discussion of their contents.” Still, Judge Cannon, whom Mr. Trump appointed in November 2020, declined to back down on having the special master vet those documents, too — and making the F.B.I. wait, at least for now, to have full access to them in its investigation. In her order, Judge Cannon took pains to describe herself as mindful of the traditional reluctance of the judicial branch to intrude on executive authority in national security matters. But she wrote that her court could not “abdicate its control over questions of privilege and does not find the government’s argument sufficiently convincing as presented.” Among other things, she went on, the government had not suggested there was any “identifiable emergency or imminent disclosure of classified information arising from” Mr. Trump’s retention of the materials. Instead, she added, “the unwarranted disclosures that float in the background have been leaks to the media after the underlying seizure.” In naming Judge Dearie as special master, Judge Cannon did not address an issue the Justice Department had flagged in saying it was open to his appointment: As a semiretired judge on senior active status, he occasionally hears cases, and active judges are not supposed to have outside employment. Judge Cannon said Mr. Trump would pay the entire cost of Judge Dearie’s compensation and expenses, along with the cost of support staff or advisers he needs, given that Mr. Trump had requested a special master. Asked about the possibility of being indicted in the investigation, Mr. Trump told a conservative radio host on Thursday that there would be “problems in this country the likes of which perhaps we’ve never seen before.” Last week, Judge Cannon issued an order announcing that she would appoint a special master to go over the materials to set aside any potentially covered by attorney-client privilege or, in a legally disputed move, executive privilege. She also prevented prosecutors from using any of the records in its investigation in the meantime. But as part of her order, Judge Cannon permitted the government to continue using the documents for a national security risk assessment and a classification review. Days later, the Justice Department asked Judge Cannon to stay parts of her order, requesting that the F.B.I. be allowed to resume investigating matters related to about 100 of the seized files marked as classified. The department argued that the bureau’s criminal investigation of the files was “inextricably linked” to the separate national-security reviews that she had said could continue. At the same time, the Justice Department told Judge Cannon that if she did not agree to its requests for a stay by Thursday, it would ask the appeals court to intervene. In effect, the government had sought a compromise, acquiescing to Judge Cannon’s decision to impose a special master and, at least temporarily, to bar F.B.I. agents and prosecutors from working further with the overwhelming majority of the seized documents and other records. In return, the Justice Department asked Judge Cannon to let its investigators continue working with a smaller batch. To make their point, lawyers for the Justice Department singled out nearly 50 empty folders bearing classified banners that were found during the search of Mar-a-Lago. The lawyers said the F.B.I. needed to investigate what happened to the contents of the folders so intelligence officials could determine whether national security had been compromised. The Office of the Director of National Intelligence has also said that after Judge Cannon’s order, it paused its risk assessment and classification review. In her ruling on Thursday, she expressed doubt about whether the government could no longer conduct such an assessment without the criminal investigation proceeding — even as she put forward a very narrow interpretation of her initial order. Judge Cannon also responded to criticism that she had put too much weight on Mr. Trump’s status as a former president in deciding that a special master with a broad mandate was justified. Critics have said that she violated the principle that the law is supposed to be evenhanded and treat everyone equally and that she has shown him special deference. She wrote that “the principles of equity require the court to consider the specific context at issue, and that consideration is inherently impacted by the position formerly held” by Mr. Trump. She added that she steadfastly believed that appointing a special master to review the seized materials and temporarily barring the government from using them was principled and necessary “to ensure at least the appearance of fairness and integrity under unprecedented circumstances.” Advertisement
Sign in Sign in Hundreds of people were arrested Saturday during demonstrations in Russia against the nation’s “partial mobilization” of troops that the Kremlin plans to throw into its invasion of Ukraine. Some who had participated in demonstrations earlier in the week had been given military summonses, state media reported. The Kremlin’s staged referendums in Ukraine — which some residents called a vote “under a gun barrel” — were underway for a second day and were scheduled to continue until Tuesday in regions controlled by Russian forces. Western leaders have condemned the orchestrated referendums as a pretext to annex swaths of the country. Here’s the latest on the war and its ripple effects across the globe. Propaganda newspapers show how Russia promoted annexation in Kharkiv: Over the months Russian troops occupied Izyum in Ukraine’s northeast, puppet authorities regularly distributed propaganda newspapers to residents, pushing a narrative of normalcy and unity even as homes and infrastructure were demolished, stores were looted, and civilians struggled to find basic provisions to survive. A trove of the Russian-language newspapers, provided to The Washington Post by a resident who said he kept them “for history,” paints a surreal version of events on the ground running in near total contradiction to the narrative both from the Ukrainian government in Kyiv and accounts from residents who survived the violent takeover of the city in March. Ukrainian forces recaptured Izyum in a surprise counteroffensive earlier this month, Siobhán O’Grady and Sergii Mukaieliants report, sparing the city from a staged referendum in an attempt to justify Russian annexation like those that began Friday in parts of Luhansk, Donetsk, Kherson and Zaporizhzhia regions. The propaganda newspapers show how Russian forces tried to take advantage of the city’s information vacuum during the occupation when cellphone and internet service was mostly cut. The papers sought to evoke nostalgia among civilians for the Soviet era, to turn residents against Ukrainian forces and to promote deep historical and cultural ties with Russia, apparently in preparation for annexation. Mary Ilyushina contributed to this report.
Liv Hanna is an up-and-coming singer-songwriter from Long Island, New York. Not too long ago, she released a delightful neo-soul single, titled, “Boy.”
“My inspiration for the song ‘Boy’ came about from observing bad behavior in my peer group and how it relates to self-respect. ‘Boy’ is about not allowing a toxic relationship to dictate you or even ruin your life. I tried to convey a message which implies whoever is listening is better off without their significant other. It encourages independence and standing up for oneself.” – Liv Hanna explained ‘Boy’ contains a relationship-based narrative and an easily absorbing vibe that will surely capture listeners’ attention. The cushy tune possesses a driving bassline groove and layered vocal harmonies capped by Liv Hanna’s sultry delivery and insightful lyrics. Written by Hanna with her co-producers, Guy Eckstine and Paul Pesco, the music production draws listeners into Hanna’s sonic realm with catchy hooks and cerebral sonic atmospheres. Furthermore, “Boy” serves as a tasty appetizer to what listeners can expect to hear from Liv Hanna as she continues to release new music and videos throughout 2022. “I use my music to convey experiences that will make my audience feel something real. I connect music to everything that I go through, and I know from first-hand experience how much a song can influence a mood and help someone. I think that’s why I’ve always been so drawn to music because no matter what is happening, I’m always pushed to feel something new when I listen to a song.” – Liv Hanna explained When the Covid-19 pandemic took hold, Liv Hanna found herself isolated from her classmates while sequestered at home. During that time, she began writing songs and released “New You,” produced by Guy Eckstine and Joe “Legacy” Lindsay. As Hanna continued to compose new songs, Eckstine called on session guitar ace, Paul Pesco (Madonna, Jennifer Lopez) to co-produce. The collaboration led to the release of the singles “Bedroom,” and “Self Made,” both showcasing Hanna’s evolution towards incorporating R&B influences into her music.
We recommend adding Liv Hanna’s “Boy” single to your favorite neo-soul playlist. Also, let us know how you feel in the comment section below. Mel Blanc’s famous catchphrase, That’s All Folks! Thanks for reading another great article on Bong Mines Entertainment – the hot spot for new music. Always remember that (P) Positive, (E) Energy, (A) Always, (C) Creates, (E) Elevation (P.E.A.C.E). Contact us on social media via Twitter, YouTube, Instagram, or Facebook, and let us know what’s going on. Disclaimer:This post, contains affiliate links, and we may be compensated if you make a purchase through links on our website. Liv Hanna Your email address will not be published.Required fields are marked *
‘Tamron Hall’ gets new logo, other updates for Season 4 ‘Jennifer Hudson’ retools ‘Ellen’ set pieces, creating inconsistent look ‘Sherri’ overhauls ‘Wendy Williams’ space with distinct look Category Sponsor Like sands through the hourglass, ‘NBC News Daily’ continues ‘Day’-driven motif U.S. morning newscasts continue extended coverage of Queen Elizabeth II Anchor’s tweet provides clues about ‘NBC News Daily’ set, graphics Category Sponsor CNN climate segment falls flat Viewers get top deck tour of new Chinese aircraft carrier thanks to AR Asharq outlines explosive Ukrainian land mine dangers using AR segment Category Sponsor Jib captures fairytale-like closing shot of Johnson’s rocky tenure as PM Viral video shows couple’s dances choreographed to NFL theme music Amazon reveals ‘Thursday Night Football’ theme music Category Sponsor CBS Sports goes cinematic in new hallmark ‘SportsCenter’ adds 38 million pixels in Studio X upgrade ESPN on ABC debuting new look, sound hallmarks during Little League World Series Category Sponsor Industry Insights: Studio robotics and camera control, part two Industry Insights: Studio robotics and camera control, part one Sony product updates focused on imaging, IP, cloud and visualization workflows Category Sponsor Illinois station remains on air even as its studio floods CBS News Detroit prepares for the elements with Next Weather Tracker Vizrt Group acquires Flowics HTML5 graphics platform CBS News Detroit prepares for the elements with Next Weather Tracker Nexstar’s WKRG 5 adds mobile weather vehicle, ‘The Beast’ Advisors Excel adds corporate broadcast studio Al Jazeera’s Studio 5 features nearly 200 Ayrton Diablo lights Case Study: How Bill Holshevnikoff lit Telemundo Sacramento Litepanels launches 2×1 Gemini panel light with 23,000 lux of output Category Sponsor Vizrt Group acquires Flowics HTML5 graphics platform Top reasons an integrator should build your broadcast facility furniture Column: The status of SDI to IP transitions and the benefits of maintaining hybrid environments… for now Category Sponsor Subscribe to NewscastStudio’s newsletter for the latest in broadcast design and engineering delivered to your inbox. From the types of jobs on offer, to what skills and experience you need to join them, here’s your essential primer in joining the rapidly evolving virtual production industry. Virtual production (VP) is rapidly becoming a popular approach across film and TV, live events, and immersive media experiences. Not only are there practical benefits – saving both time and cost when compared to expensive location shoots – but it also opens up a whole new world of creative possibilities for any kind of media production. With the industry rapidly evolving, roles in VP are becoming increasingly in demand, opening up a range of opportunities for both newcomers and established industry professionals. In this article, we’re sharing some examples of key roles in VP and discussing tips on breaking into the industry as a newcomer. With these new roles constantly evolving, it’s clear that there is plenty of opportunity to get involved with the ever-expanding virtual production world. But how do you actually get started with a career in virtual production? As with any industry, networking is a good place to start. However, it’s also a good idea to familiarize yourself with the virtual production pipeline. Having an understanding of each element of the production, even those you’re not directly involved with – such as video I/O, real-time animation, technical support, and stage skills – will give you an advantage in creating a seamless workflow. And if you work on the creative side, then a showreel is essential for showcasing your work. Teamwork and communication are particularly important and often undervalued skills for the virtual production environment, says Erik Beaumont, head of mixed reality (MR) at The Famous Group (TFG), a production company specializing in virtual and augmented reality for sports and live events. Erik also highlights the advantage of having a traditional production background. “Production timelines and deadlines are stacked slightly differently. We emphasize different things like how the dailies work and cutoff dates for approvals, but if you have the basic toolset, you’ll adjust fairly seamlessly,” says Erik. He also advises that knowing your way around a real-time engine will put you in a good position, and that this is not as hard as it sounds. “Pick a game engine of choice and just do something in it. People imagine a high threshold of how complicated it is, but the reality is different,” says Erik. Spanish 3D artist Fernando Trueba Llano, a technical artist at Televisión Canaria, agrees that real-time engines are a good starting point for those who want to get into virtual production but don’t know where to start. “My recommendation would be to start studying the basics of 3D and focus on Unreal Engine,” says Fernando. “Dedicate personal time to dig in and learn as much as possible. […] And finally, put into practice what you have learned and create demos of your capabilities with the engine.” If you’re interested in gaining new skills in VP from a traditional production background, or if you’d like to transfer your experience in gaming, VFX, or real-time engines, here’s a taster of some of the new jobs and skills currently needed in the ever-evolving virtual production industry. The Virtual Production Supervisor is a leadership role, taking charge of the entire virtual production set. People in this role can expect to act as a bridge between different sections of the crew. This requires strong people skills – and you’ll also need an excellent understanding of the tech involved. This is an ideal role for producers, or those with a background in VFX, such as a VFX supervisor. A virtual production volume – otherwise known as an XR volume or VP stage – is made up of many large LED panels that display media content. This can be anything from stills and 2D footage to real-time 3D graphics generated by a game engine. These volumes need someone to oversee the content piped into these screens, where the Volume Operator comes in. Often working with assistants, depending on the production size, the Volume Operator is usually someone with experience in creating real-time graphics on gaming engines such as Unreal Engine or Unity. As well as having someone to operate the volume, virtual productions require someone to manage and maintain the screens themselves. LED panels are a key piece of the rig in a VP environment so it is essential to have an LED Engineer, otherwise known as an LED Technician, on-set to ensure they work correctly and consistently. LEDs have been used across live events and broadcasts for some time, so many AV technicians will find they already have the required skills to become an LED Engineer. Other relevant skills include experience in motion capture and camera tracking systems, plus knowledge of Unreal Engine and other real-time tools. In the visual effects industry, VFX supervisors take charge of an entire project, managing the people, workflows, and timelines for delivery. This is not an entirely new role, but has evolved within the virtual production world. In VP, a VFX Supervisor is responsible for all the visual effects on a real-time production. This role works across the creative side but also has a solid understanding of the technical aspects involved, especially newer innovations like real-time technology. Another leadership role, this one focuses on motion capture. Like the VFX Supervisor, this role has existed for some time but has now expanded to incorporate the real-time environment. Again, working knowledge of motion capture and the ability to work with camera tracking systems is essential. As the name suggests, this person operates a virtual camera using an external device such as a tablet. A good understanding of cinematography is important, as well as the ability to keep up to date with all the latest equipment and software on offer. This is also an excellent role for people with experience in creating computer-generated animations using game engines. Real-time game engines, such as Unreal Engine and Unity, are becoming an increasingly essential part of the virtual production pipeline. The Engine Operator is responsible for operating the real-time engine being used in the production. About Carina Schoo, PixotopeCarina is an experienced communications professional with a track record in the marketing of immersive imaging technologies and virtual solutions. Carina joined the virtual production software company Pixotope as Education Program Manager. Her primary responsibility is to design, manage and execute the Pixotope Education Program (PEP). As a mediator between educational institutions and the virtual production industry, she identifies shortages and needs on both sides, breaking down barriers to the wide adoption and growth of virtual production. Before joining Pixotope, Carina worked as a Project Manager for one of the renowned German Fraunhofer Institutes, the Fraunhofer Heinrich Hertz Institute in Berlin (DE), and as Communications Consultant for VRINN Immersive Learning Cluster, Hamar (NO). Carina holds a Master’s degree in Communications and Languages from the Technische Universität Berlin. employment opportunity, jobs, motion graphic jobs, Pixotope, Professional Development & Training, The Famous Group, Virtual Production Broadcast Automation, Broadcast Engineering News, Featured, Featured Column, IP Based Production, Jobs, Virtual Production 101
Thank you for visiting nature.com. You are using a browser version with limited support for CSS. To obtain the best experience, we recommend you use a more up to date browser (or turn off compatibility mode in Internet Explorer). In the meantime, to ensure continued support, we are displaying the site without styles and JavaScript. Advertisement Scientific Reportsvolume 12, Article number: 15938 (2022) Cite this article Metrics details Floor cleaning robots are widely used in public places like food courts, hospitals, and malls to perform frequent cleaning tasks. However, frequent cleaning tasks adversely impact the robot’s performance and utilize more cleaning accessories (such as brush, scrubber, and mopping pad). This work proposes a novel selective area cleaning/spot cleaning framework for indoor floor cleaning robots using RGB-D vision sensor-based Closed Circuit Television (CCTV) network, deep learning algorithms, and an optimal complete waypoints path planning method. In this scheme, the robot will clean only dirty areas instead of the whole region. The selective area cleaning/spot cleaning region is identified based on the combination of two strategies: tracing the human traffic patterns and detecting stains and trash on the floor. Here, a deep Simple Online and Real-time Tracking (SORT) human tracking algorithm was used to trace the high human traffic region and Single Shot Detector (SSD) MobileNet object detection framework for detecting the dirty region. Further, optimal shortest waypoint coverage path planning using evolutionary-based optimization was incorporated to traverse the robot efficiently to the designated selective area cleaning/spot cleaning regions. The experimental results show that the SSD MobileNet algorithm scored 90% accuracy for stain and trash detection on the floor. Further, compared to conventional methods, the evolutionary-based optimization path planning scheme reduces 15% percent of navigation time and 10% percent of energy consumption. Generally, human traffic is heavy on commercial premises like shopping malls, food courts, community clubs, and hospitals. Therefore, the chances of accumulating trash, stains (footprint stains and other forms of stains), and debris are quite high, raising safety and hygiene concerns. Hence, frequent cleaning is essential in commercial premises in pandemic situations like COVID-19. Due to long working hours, low wages, and unwillingness to work as a cleaner, workforce shortage has been a constant problem for cleaning and maintenance tasks in commercial premises1,2. In recent years, mobile cleaning robots have been widely used to clean and maintain commercial premises and help overcome the workforce shortage. It performs the cleaning task in public premises using two cleaning modes: auto cleaning/scheduled cleaning mode and selective area cleaning/spot cleaning mode2,3,4,5. Here, the auto cleaning/scheduled cleaning mode cleans the given workspace autonomously once a day or at a scheduled time interval using a pre-build floor map. In selective area cleaning/spot cleaning mode, the robot will clean only dirty areas instead of cleaning the whole region. In contrast with auto cleaning/scheduled cleaning mode, the selective area cleaning/spot cleaning mode could save energy by avoiding non-dirty areas, reducing the cleaning time, and enhancing the lifetime of the robot6. However, the selective area cleaning/spot cleaning mode hasn’t been designed with autonomous operation, where the robot requires human assistance to perform the selective area cleaning/spot cleaning. Moreover, human-assisted selective area cleaning or spot cleaning is labor-intensive and time-consuming for larger workspaces. The cleaning supervisor needs to continuously monitor or inspect the environment to enable selective area cleaning/spot cleaning mode (according to human traffic in the environment or trash and stains detection). Computer vision-based autonomous selective area cleaning/spot cleaning is a viable solution for overcoming the shortcomings mentioned above. Recently, Machine Learning (ML) and Deep Learning (DL) based computer vision algorithms are widely used for mobile cleaning robots for stain and trash detection and path planning tasks7,8,9. However, selective area cleaning/spot cleaning using onboard robot vision systems and generating the optimal path generation has a lot of practical challenges. Searching and finding the dirty region itself increases the energy consumption and processing time by scanning the entire area of operation. Further, monitoring human traffic from a robot perspective and computing the selective area cleaning/spot cleaning region took more computation time and power. Hence, there is a need for a novel and scalable approach to overcome the challenges mentioned above in the selective area cleaning/spot cleaning method. Therefore, this article proposes a novel selective area cleaning/spot cleaning framework for indoor floor cleaning robots using RGB-D vision sensor based Closed Circuit Television (CCTV) network, deep learning algorithm, and optimal complete waypoints path planning algorithm. Furthermore, the main contributions of this paper are divided threefold: Design and development of selective area cleaning/spot cleaning using deep learning-based computer vision algorithm and RGB-D vision sensor network. The deep learning algorithms find the selective area cleaning/spot cleaning region based on detecting stains and trash on the floor and tracing the human traffic patterns (common space: hall, entrance, and hallway/entryway). Compute the 3D location of stain and trash in world coordinates to estimate the complete waypoint coverage path planning by evolutionary methods to drive the cleaning robot to a selective area cleaning/spot cleaning. Validate the efficiency of selective area cleaning/spot cleaning framework in the real workspace with in-house developed reconfigurable floor cleaning robot hTetro. The manuscript is organized as follows—section “Related work” elaborates the related works, and the proposed system is presented in section “Overview of the proposed system”. Finally, section “Experimental results” provides the experimental results, followed by the conclusion and remarks of this work. This section presents the various dirt, stain, and trash detection schemes reported in the literature with detail summery (Table 1) and the optimal path planning methods used for cleaning robots. In10 Andersen et al. proposed a floor cleaning robot with a cleanness sensor using a computer vision algorithm and LED illumination. The sensor identifies dirty areas by analyzing surface images and producing pixel-by-pixel cleanness maps, applying a multivariable statistical approach. Borman et al.11,12 proposed a spectral residual filtering-based method for dirt detection. The dust threshold for various floor patterns is fixed based on maximal and minimal filter response. However, the dirt detection ratio is varied upon surface types. Mud and dirt on the floor are identified and classified for cleaning robots using Maximally Stable Extremal Regions (MSER) and Minimal Canny edge detection algorithms13. Lee and Banerjee14 suggested a solution for the overall cleaning schedule, which also generates an effective path for each cleaning cycle. Simulation-based Optimisation (SO) technique is applied for floor cleaning to avoid redundant paths and maintain tolerable dirt particle levels. In6 vision-based dirt detection was proposed for floor cleaning robot hTetro. Here, the authors use a periodic pattern detection filter to identify the dirt region on the floor and a tilling algorithm for generating the cleaning pattern. Grunauer et al.15 proposed an algorithm to detect dust spots based on Gaussian Mixture Model (GMM) applied to RGB images. This supports distinguishing the dust spots from the floor surface. Martinez et al.16 proposed a vision-based dust detection technique for the planar surface. The median filter and the thresholding technique were applied to distinguish the dust and the floor surface. Further, RANSAC algorithm was adopted to detect plane surfaces. However, as mentioned above, the scheme has significant practical limitations; for instance, the heavy detection of dirt depends on the floor background and cannot distinguish the dirt classes like trash or stain11,12,13. Deep Learning (DL) based object detection is an emerging technique. Nowadays, it has been widely utilized in the autonomous robot vision system, abandoned object detection in surveillance applications8,9, human and vehicle tracking applications17,18, to detect stains and trash in cleaning robots, classify garbage in waste management. In19 author evaluate the efficiency of various deep learning-based object detection framework for marine trash detection. The authors report that the Single Shot Detector (SSD) architecture has high detection accuracy than the Yolo v2 and Tiny Yolo object detection models. GoogLeNet-Overfeat object detection model was trained for outdoor trash detection proposed by Rad et al.20. Here, the detection framework was trained with 18000 trash images containing waste papers, metal/plastic cans, and leaves. The trained model obtained a maximum of 77.3 % precision for detecting trash on the street. Ramalingam et al.7 proposed a debris detection and classification framework for floor cleaning robot application. The authors7 train the SSD MobileNet object detection algorithm with debris image dataset to detect and classify the trash and stains on the floor. Zhihong et al.,21 proposed an automatic trash sorting system using Region Proposal Network (RPN) and VGG-16 deep learning model. The authors report that the trained model had 3% miss detection and 9% false detection. Gaurav et al.21, proposed a smartphone app-based outdoor garbage localization technique where AlexNet CNN was trained to detect the outdoor garbage and detect the outdoor trash with (87%) detection accuracy. Yin et al.2 proposed Human Support Robot (HSR) based on deep learning for cleaning the tables. A darknet framework-based 16-layer CNN framework was developed. The model achieved 95% accuracy in detecting food strains and trash on the surface of the table. Further, a similar autonomous robot was developed using deep learning architecture, which has the capability to produce two-dimension trajectories from human kinesthetic instances22,23. Apart from dirt, stain, and trash detection, path planning is also a key function for floor cleaning robots to achieve efficient cleaning. In the literature, path planning for cleaning robots was widely studied. Generally, spiral and zigzag patterns are widely used to generate the path for cleaning robots, aiming to maximize the area’s coverage. However, these patterns have significant limitations in covering the constrained areas, such as narrow space, and are only suitable for fixed morphology platforms7. Further, computing the optimal shortest path is another key challenge for the selective area cleaning/spot cleaning task. Reconfigurable morphology robots can cover the maximum area and arbitrary workspace compared with a fixed morphology robot and are more suitable for selective/ spot-cleaning tasks. Self-reconfigurable robots have attracted significant attention, and the development of autonomy systems mostly focused on autonomous motion control and mechanism design. There are only a few works in path planning for self-reconfigurable robots, e.g., the work in24 proposes a complete coverage path planning model trained using deep reinforcement learning (RL) for the tetromino based reconfigurable robot platform to simultaneously generate the optimal set of shapes for any pretrained. Research on path planning so far focuses on fixed-morphology robots and considered robots as a single point. But, representative path planning algorithms can be broadly classified as classical graph search algorithms (Dijkstra, A*, D*, and D* Lite)25,26,27,28, bio-inspired search (genetic algorithm, ant colony optimization, and particle swarm optimization)29,30,31,32,33,34,35, geometric algorithms (probabilistic road map, visibility graph, rapid-exploring random tree, cell decomposition, Voronoi graph)36,37,38,39,40,41. However, selective area cleaning/spot cleaning path planning for re-configurable floor cleaning robots is a new approach. It has not been explored yet. This research describes the optimal shortest waypoint coverage path planning method using evolutionary-based optimization technique for re-configurable floor cleaning robot hTetro to execute the selective area cleaning/spot cleaning task. Figure 1 shows the overview of our selective area cleaning/spot cleaning framework with a functional block diagram. It is developed for floor cleaning robot indoor selective area cleaning/spot cleaning task. Generally, high human traffic areas are more likely to accumulate more trash and foot stains. Hence, two strategies are combined to efficiently find the indoor environment’s selective area cleaning/spot cleaning regions. It includes tracing the human traffic patterns and detection of stains, foot stains, and trash on the floor. The proposed system functional block diagram is composed of an image data collection module from the RGB-D vision sensor network, deep learning-based computer vision algorithms, and an optimal path planning module for the hTetro robot. WiFi-enabled surveillance camera setup (Realsense D345 fitted in roof corners) captures human movements indoors and continuously captures the floor images. The camera system is fixed in the corners of the roof, and the Field of View (FoV) is calibrated with the 3D map built by the hTetro robot base frame. The cameras are connected to an external server through a WiFi router to transfer the captured video stream’s. A deepSORT human tracking algorithm was used to trace the human traffic pattern. SSD Mobilenet object detection algorithm was trained to detect foot stains on the high human traffic region, common stains, and trash on the floor. The selective area cleaning/spot cleaning algorithm is run on an external server built with a high-performance GPU. The server collects the indoor images continuously through a WiFi router and performs the human traffic pattern detection analysis, stains, and trash detection task. According to the human traffic pattern tracing, stains, and trash detected on the floor, the framework generates the navigation strategy and send the way point coordinates to hTetro robot to perform the selective area cleaning/spot cleaning task. The robot uses waypoint information (computed through image coordinate to robot footprint coordinate) and odometry data to reach the selective area cleaning/spot cleaning location and perform the cleaning task. The details of each component and integration methods are described as follows. Overview of the proposed system. The Deep SORT is an improved version of the Simple Online and Real-time Tracking (SORT) algorithm. Generally, deep sort is used for human tracking applications. In our work, Deep SORT is used to monitor the human traffic pattern tracing in indoors through RGB-D vision sensor collected image and map the high traffic area to identify the selective area cleaning/spot cleaning region. The Deep SORT tracking framework was built using the hypothesis tracking technique with the Kalman filtering algorithm and DL-based association metric approach. Further, the Hungarian algorithm is utilized to resolve the uncertainty between the estimated Kalman state and the newly received measuring value. The tracking algorithm uses the appearance data to improve the performance of sort42. In this work, the bounding box coordinates in image plane (X(_{min}),Y(_{min}) and X(_{max}) and Y(_{max})) of human detection are passed to Deep SORT with image frame for tracking the human movements. According to bounding box coordinates and object appearance, deep SORT assigns each human detection ID and performs the tracking. A selective area cleaning/spot cleaning algorithm used the tracked information to compute the cleaning spot. A Single Shot Detector (SSD) MobileNet V2 end-to-end object detection framework is adopted to detect the stains, foot stains, and trash on the floor. The functional block diagram of SSD MobileNet is shown in Fig. 2. Here, feature extraction is done using the MobileNet model. Bounding box prediction is made using a meta-architecture SSD. While training, RMSprop algorithm43 is used for loss optimization. The framework was trained using a transfer learning scheme; the last layer of the detector head is modified to detect the stains, foot stains, and trash. SSD MobileNet V2. MobileNet v2 is used as the base network that performs feature extraction tasks suitable for mobile and edge devices. Figure 2 shows the MobileNet v2 architecture. It comprises multiple residual bottleneck layers. These layers use (3times 3) in depthwise convolution layers, which are more efficient than standard convolution layers. They also employ (1times 1) convolutions instead. The architecture also uses ReLU6 layers, which are ReLU layers with an upper limit of 6. The upper limit prevents the outputs from scaling to a huge value, reducing the computation cost. Single-Shot Detector (SSD) is an object detection algorithm. It outputs the object’s location through a bounding box in an image with the confidence of the prediction. The bounding box coordinates have been translated into real-world coordinates and fed to a trajectory planning algorithm to generate the selective area cleaning/spot cleaning path. The SSD algorithm uses the MobileNet feature map to generate the anchor boxes. The final few layers (feature map) from the feature extractor are used to predict trained objects’ locations. In the SSD architecture, the input is passed through different convolution layers of different sizes. These layers decrease in size progressively through the network. The purpose of these layers is to enable the network to detect objects of different shapes and sizes. While training, confidence loss (L_{confidence}) and localization loss (L_{location}) Eq. (1) was calculated for each prediction. The prediction error of class and confidence is given by confidence loss. The localization loss is a smooth loss between the predicted bounding box value and the ground truth value. The value (alpha ) is used to reduce the overall loss’s influence and balance confidence and location loss. Root Mean Squared gradient descent algorithm (RMS) is used for optimizing both the losses. The weights (w_t) are computed at any time t using the gradient of loss L, (g_t) and gradient of the gradient (v_t) Eqs. (2)–(4). The hyperparameter (beta = 0.9, eta = 0.02) are utilized for estimating the momentum and gradient values, while a small value near to zero (epsilon ) is used for avoiding divide-by-zero errors. After finding the 2D pixel coordinates in the RGB image frame of stain, trash, and human traffic pattern, the system will derive the world frame’s corresponding 3D position. Since, the perception system is a stereo camera with both an RGB image sensor and a depth image sensor, they are of the same resolution, and each pixel in the RGB image corresponds to the pixel in the depth image. This enables us to map the dirt object’s localized pixel coordinates to their depth value. When the depth images are subscribed, the image will be filtered via an adaptive directional filter44 to remove noise. After filtering the depth image, the depth value of the dirt objects, (d_o), has been derived by Eq. (5) as follows: where, (Omega ) represents the sum of pixels within a (10 times 10) window, and (d_i) represents the value of the depth in the pixel. The dirt objects in real-world coordinates will be estimated by converting the X and Y pixel coordinate system to x and y world coordinate system built by the Robot Lidar sensor. RGB-D Sensor parameters are derived through camera calibration techniques to give the camera an intrinsic and extrinsic matrix45. Camera calibration methods give us the focal length, (f_x), and (f_y), of the RealSense RGB-D sensor and the optical center, (c_x), and (c_y), of the RealSense RGB-D sensor in its respective x and y coordinate to get the intrinsic camera matrix, I. The RealSense RGB-D sensor in-built functions also provide us with the translation vector, K, and rotation vector, Q. The extrinsic matrix, S, can be derived where (S = [Q K]). Further, it will convert from the pixel coordinate system to the world coordinate system through Equation (6). where P is the world coordinates, p is the pixel coordinates. hTetro is an in-house developed re-configurable floor cleaning robot (Fig. 4). This robot consists of a chain-type with four cube shape modules connected by three hinges at the corner of blocks, as shown in Fig. 3. In hTetro, blocks 1, 3, and 4 each hold a cleaning module, while block 2 contains the primary electronic circuits. The robot blocks could be easy to remove and add a degree of freedom. The hinges permit the hTetro robot in shape-transferring and a couple of configurations. The shape-shifting allows the robot to cover the constrained space more efficiently than fixed-form robots. For instance, the robot can cover the bigger space with the default O shape and change shapes flexibly from the O to I shape to cover the narrow spaces. The three hinges connected between robot blocks are used for shape-shifting during the reconfiguration. The locomotion modules at each block are programmed to operate synchronously with others according to the robot’s transformation, and each of the modules is amenable for steering and moving the hTetro. Each block contains two geared DC motors with encoders for balance locomotion. The operation voltage rating of the DC motors is 7.4V. In hTetro, a potentiometer type absolute encoder was used in each block to sense the shape change action and block’s heading angle. When the hTetro is involved in the transformation actions, the servos located at the hinges drive the modules by rotation clockwise and anticlockwise to do the reconfiguration into seven distinct shapes –‘I, L, S, T, Z, J, O’, as shown in Fig. 3. The low-level controller (Arduino mega) was used to measure the output current from the absolute encoder through the A/D Input pin and fine-tunes the shape change action. This sensing data helps ensure that the units are aligned and moving in the same direction. The servo motors run at 14.8V, and the high torque is 77 kg. cm. The servo has enough torque to hold the hTetro block masses in morphologically changing and fastening the blocks in locomotion. hTetro hardware architecture was developed with a single-board computer Intel compute stick and low-level micro-controller Arduino mega 2560 (Fig. 4). The Intel compute stick is powered with an Intel Core m3 processor, 4GB of memory, and 64GB of eMMC flash storage. It was used as an hTetro central processing unit, runs with an operating system of Ubuntu 20.04, and uses ROS Melodic46 as middleware. The hTetro navigation algorithms run alongside the ROS middleware in the compute stick and control all the autonomy-related operations of the hTetro. The navigation algorithm receives the waypoint information from the remote/local server through on board WiFi module and generates the control command to the low-level control unit to execute the selective area cleaning/spot cleaning task. Arduino-Mega was used as a low-level controller. It works at 5 volt supply voltage and operates at 16 Mhz clock frequency. The controller receives the commands from the central processing unit through ROS serial bridge function and generates the appropriate actions for the motor drives and other local electronic components. The rosserial ROS package uses Arduino’s universal asynchronous receiver/transmitter (UART) communication and converts the board to a ROS node that can output ROS messages and subscribe to messages as well. Seven configurations of hTetro. hTetro hardware components. The 3D points at the centers of detected objects are defined as waypoints the robot needs to visit to do the appropriate selective area cleaning/spot cleaning region. The robot will derive the optimal navigation trajectories defined as Complete Waypoint Coverage Planning (CWCP) to visit all the waypoints. With N unsequenced waypoints detected from the perception unit, the navigation trajectory (eta ) is defined as follows: (eta ~=~{(W_1^s, W_1^g), (W_2^s, W_2^g) …, (W_N^s, W_N^g)}) The trajectory (eta ) consists of pairs of waypoints with the directions which indicate the order of navigation. The initial waypoint is labeled (W_1^s), and the final waypoint is labeled (W_N^g). This trajectory representation visits each waypoint among N waypoints once. The cost to navigate from source waypoint to destination waypoint equals to summation of mass of each robot (m_i) block multiplied with 3D displacement to move blocks from source ((x^s_i,y^s_i,z^s_i)) to goal ((x^g_i,y^g_i,z^g_i)) as shown in Eq. (7). The total cost of the trajectory can be summarized by all the waypoint pair components as shown in Eq. (8). The Pareto trajectory is defined as (widehat{eta }), and the objective of the proposed CWPP problem is derived by Eq. (9). There are many possibilities to form the trajectories and find the optimal route to minimize the fitness function; the classic Travelling Salesman Problem (TSP) model can be considered an NP-hard problem. Similarly, brute force search can be used for iterating every possible path with factorial time complexity O(n!), But performance gradually decreases with the large input data size. Dynamic programming through Held-Karp algorithm47 reduces the complexity of TSP to O((n^22^n)) time. However, the method is still inappropriate for the presented scenario where multiple detected waypoints are in the working workspace. Evolutionary approach Ant Colony Optimization (ACO)48,49 is adopted to find the optimal trajectory connecting the waypoints, (hat{eta }) in Eq. (9) within a reasonable time. Optimization based on probabilistic techniques are the main idea of ACO. By tuning the ant colony decisions at the waypoint and the constant updates on the pheromones left along the temporary trajectory, the ACO algorithm has proven to be a feasible method to derive the Pareto-optimal solution of the TSP while eliminating the calculation burden. This section presents the experimental procedure and outcome of the selective area cleaning/spot cleaning framework tested on the hTetro robot. The algorithm has two pre-processing steps: training the trash and stain detection framework using a custom dataset and mapping the indoor environment for hTetro autonomous navigation. The dataset was prepared in-house with different image resolutions. The dataset has four classes (Stain, Foot stain, Trash and Human); each class has 1200 images. Most of the images are created in-house with various floor backgrounds, and few images are collected online through bing image search. Here, in-house collected images are captured in an overhead perspective with a Realsense RGBD camera with a different angle and different illumination conditions. Then, the captured images are labeled for training the detection framework (SSD MobileNet). Further, to reduce the CNN learning rate and avoid over-fitting. The data augmentation (rotation, scaling, and flipping) is applied in collected images. The standard method of the K-fold (here K = 10) cross-validation process is used to evaluate the detection model. In K-fold cross-validation, the labeled images are split into ten sets, and nine sets were used to train the detection network, and one set is utilized for evaluation. These steps run for ten rounds to ensure all the data were used for both training and testing to eliminate the biasing conditions. This process is done to remove any bias due to the particular training and testing data set to split. The experimental results are obtained from the detection model with reasonable accuracy. The deep learning models were developed in Tensor-flow 1.9 Ubuntu 18.04 version and trained using the following hardware configuration Intel core i7-8700k, 64 GB RAM, and Nvidia GeForce GTX 1080 Ti Graphics Cards. Standard statistical measures such as accuracy (10), precision (11), recall (12) and (F_{measure}) (13) were used to evaluate the proposed algorithm through confusion matrix elements. Here, tp, fp, tn, fn represents the true positives, false positives, true negatives, and false negatives, respectively, as per the standard confusion matrix. The selective area cleaning/spot cleaning framework was validated in three different indoor environments with the sizes of (10 times 10, 8 times 8, 15 times 8 ) feet. The overhead cameras were fixed corner of the roof in the testbed for tracing the human movements and capturing the floor images. The captured floor images are transferred to the external server, running a selective area cleaning/spot cleaning framework. The experiment was carried out with different lighting conditions, and results are shown in Figs. 5 and 6. In this trial, the overhead camera run at 30fps, and the image resolution was (640times 480) pixels. The floor image was captured at 7 feet height from the ground, and the camera head is inclined at an angle of 45 degrees downwards. Real-time detection of stain, foot stain, trash. Human movement tracking, (a–c) human movements and (d) tracking result. The stain is detected by a light turquoise color bound box, foot stains were marked as white rectangle box and trash marked by the sky blue bounding box. Figures 5 and 6 shows the human traffic pattern detection results. Here, the human movements were tracked by bounding boxes, and the traffic pattern is indicated in the orange line. The experiment results indicate that the selective/ spot cleaning framework detects the human, stain, and trash with a higher confidence level of (92%), (90%), 95%, and (98%), respectively. Further, the model detection accuracy was estimated by statistical measures, which are given in Table 2. The statistical measurement result shows that the framework has identified the stain with an average of 93.44%, foot stains with 91.69%, trash with 93.0 %, and human with 97.0%, respectively. In this experiment, we observe that stain and foot stain detection confidence level and statistical measure values are relatively low compared to other classes due to less visibility of objects and complex texture shape. Further, the computation cost of the proposed system was estimated via inference time; in this test, the framework took 0.05 seconds to process the (640 times 480) images. The statistical study ensures that the proposed system was stable for different lighting conditions and also work in realtime. The efficiency of the SSD mobilenet stain trash detection was evaluated with other benchmark object detection algorithms include Faster RCNN ResNet50, Faster RCNN Inception51, and Yolo v2 frameworks. The same dataset was used for estimating the detection and classification accuracy of three networks for a period at the same time. Statistical measure parameter was used to compare the performance model. Table 3 shows statistical measure results of each framework. In addition to that, timing analysis was performed to calculate the detection time taken by each network. NVIDIA Quadro P4000 graphic card was used for testing the proposed algorithm, as shown in Table 4. Best detection accuracy was obtained using Faster RCNN ResNet and Faster RCNN inception compared to other models. Yolo v2 inference time is comparatively low but showed poor detection accuracy. SSD-MobileNet has obtained a better trade-off between detection accuracy and inference time. Hence, SSD- MobileNet shows optimum results when used in realtime applications for object detection. Optimized SSD MobileNet is highly suitable for low-power resource-constrained embedded systems, making it suitable for realtime applications. We validated the efficiency and performance of the selective area cleaning/spot cleaning method in terms of navigation efficiency by deploying the cleaning robot system to clean optimally the detected tracked human traces in the selected indoor testbed sites. Specifically, depending on the human interaction activity in the environment, a location map is constructed on the grid cells by the proposed framework. The location map distribution result is used as input for a hTetro reconfigurable cleaning robot to decide navigation strategies optimally. The Complete Waypoints Coverage Planning (CWCP) framework derives the smallest costweight and energy consumption for real environments testbed. The trajectories denoted as red linking arrows generated by all teed methods including zigzag, spiral, greedy search with 100 iterations, and ACO algorithms for all testbed workspace-1 with 9 detected waypoints and workspace-2 with 11 detected waypoints are shown in Figs. 7 and 8, respectively. In the experiment, the best parameter values are found by the experimental approach by 200 trials. after tunning, the ACO parameters set is evaporation probability = 0.9, and ant agents = 220. The terminal’s criteria are triggered when the costweight during execution is not improved for ten iterations or the execution loop runs over the 500 iterations. The trajectories of the tested method for workspace-1. (a) zigzag; (b) spiral; (c) greedy search; (d) ACO. The trajectories of the tested method for workspace-2. (a) zigzag; (b) spiral; (c) greedy search; (d) ACO. The trajectories with found costweight and the time to generate as well as the running time to complete these found trajectories of the tested method for the two testbed workspaces are represented in Table 5, respectively. Because of the straightforward approach in generating the paths, the path generation time of the zigzag and the spiral are smaller than Greedy Search and ACO, but the zigzag and spiral methods link the defined locations by position-wise orders; hence the costweight is greater than greedy search methods and significantly greater than ACO based Complete Waypoints Path Planning (CWPP). Noted that a greedy algorithm is an algorithm that follows the problem-solving heuristic of making the locally optimal choice at each stage. Since it may be stuck at local minimal so we run the greedy algorithm for 100 iteration with random beginning waypoint and select the best solution. That makes that greed search requires more path generation time. In terms of running time when deploying the found trajectory to the real robot, the Zigzag and Spiral need more time to cover the defined waypoint than the greedy search. Together with the least costweight, the running time of ACO-based CWPP is the shortest one. After the perception system has defined the waypoint locations in real testbed sites, the energy efficiency during the selective area cleaning/spot cleaning process is validated by recording in realtime the energy consumption. The current sensors connected to the main lithium-ion battery with the specs of 14.4 V, 3000 mAh are logged during robot operation. These current values are integrated with the running time to find power consumption. In the selective area cleaning/spot cleaning mode, the hTetro is set at O shape and to clear these waypoints in order. The robot can change to I shape to access the narrow space area by the environment evaluation from the Lidar sensor. The action of shape-changing is adapted to a dynamic environment. The robot modules such as perception, locomotion, and shape-shifting communicate under the controls by the ROS system52. To archive the smooth locomotion with the different kinematic design of hTetro, the moving command generated by the PID controller is sent to motor drivers to issue appropriate velocity for the DC motors. Specifically, the robot should keep the planned trajectories and overcome the disturbances while colliding with static and dynamic obstacles. These tasks are significant challenges since the synchronization between hTetro blocks locomotion must be accomplished. To fulfill the kinematic constraints, the control method is based on the Instantaneous Center of Rotation (ICR). The placement of ICR makes use of the desired positions and velocities information provided by the central computing unit based stains pattern. After that, the corresponding steering angle and required individual velocity are calculated based on the ICR location. A velocity regulator is then used to limit the velocity of each motor. Due to the placement of LIDAR on the second module’s chassis, the orientation of the whole robot is defined according to it. The instantaneous center of rotation’s desired location is defined based on the desired position, current position, and the desired velocity. It is represented in the polar coordinate using to avoid numerical singularity. The hTetro locates itself within the pre-built map using enhanced extended Kalman filter(EKF)53 for multi-sensor fusion makes sure hTetro can navigate from source and destination goad correctly even if sensors noise is received, or any perception sensors struggle the malfunction issues. From Table 5, if the robot clears the found path of the method with a smaller costweight value, the less energy spent is observed. Specifically, since producing the longest costweight, the zigzag draws the highest energy, then the spiral follows the following position with a slight amount lower. The best CWCP method in both energy and time saving is ACO. It yields about 10% and 15% lower than the greedy search in energy and time spent, respectively. The results ensure that the proposed CWCP with ACO is possible for selective area cleaning/spot cleaning by hTetro. This work proposed a selective area cleaning/spot cleaning technique for reconfigurable floor cleaning robot hTetro using deep learning-based computer vision algorithms and an optimal complete waypoints path planning method. SSD MobileNet object detection algorithm and Deep SORT real-time human tracking algorithm were used to find the human traffic patterns and detect the stains, foot stains, and trash on the floor. The proposed scheme was tested with two different testbeds with hTetro reconfigurable floor cleaning robot and evolutionary optimization based optimal trajectory generation algorithm. The experimental results showed that the trained SSD model detects the stains, foot stains, and trash on the floor with a high confidence score, and its result is used to find the selective area cleaning/spot cleaning region. Further, the SSD MobileNet framework’s stain and trash detection efficiency was evaluated with other CNN-based object detection algorithms and observed that SSD MobileNet obtained a better trade-off between detection accuracy and low inference time for detection of stains and trash. The overall experimental results show that the proposed framework is more suitable for enabling the autonomous selective area cleaning/spot cleaning function for the reconfigurable floor cleaning robot hTetro. ‘The datasets used and/or analysed during the current study available from the corresponding author on reasonable request.’ Correspondence and requests for materials should be addressed to B.R. The 5 most unwanted jobs in singapore, accessed 6 Jan 2020; https://sg.finance.yahoo.com/news/5-most-unwanted-jobs-singapore-160000715.html. Yin, J. et al. Table cleaning task by human support robot using deep learning technique. Sensors20, 5. https://doi.org/10.3390/s20061698 (2020). Article Google Scholar Murdan, A. P. & Ramkissoon, P. K. A smart autonomous floor cleaner with an android-based controller. In 2020 3rd International Conference on Emerging Trends in Electrical, Electronic and Communications Engineering (ELECOM), 235–239, https://doi.org/10.1109/ELECOM49001.2020.9297006 (2020). Deepa, G. et al. Robovac-automatic floor cleaning robot. In 2021 Third International Conference on Inventive Research in Computing Applications (ICIRCA), 1–4, https://doi.org/10.1109/ICIRCA51532.2021.9544914 (2021). Ramalingam, B. et al. Deep learning based pavement inspection using self-reconfigurable robot. Sensors21, 5. https://doi.org/10.3390/s21082595 (2021). Article Google Scholar Ramalingam, B., Veerajagadheswar, P., Ilyas, M., Elara, M. R. & Manimuthu, A. Vision-Based Dirt Detection and Adaptive Tiling Scheme for Selective Area Coverage. Journal of Sensors. https://doi.org/10.1155/2018/3035128 (2018). Ramalingam, B., Lakshmanan, A.K., Ilyas, M., Le, A.V. & Elara, M.R. Cascaded machine-learning technique for debris classification in floor-cleaning robot application (2018). Shin, M., Paik, W., Kim, B. & Hwang, S. An iot platform with monitoring robot applying cnn-based context-aware learning. Sensors19, 2525. https://doi.org/10.3390/s19112525 (2019). ADSArticlePubMed Central Google Scholar Koo, J. H., Cho, S. W., Baek, N. R., Kim, M. C. & Park, K. R. Cnn-based multimodal human recognition in surveillance environments. Sensors18, 3040. https://doi.org/10.3390/s18093040 (2018). ADSArticlePubMed Central Google Scholar Andersen, N.A., Braithwaite, I.D., Blanke, M. & Sorensen, T. Combining a novel computer vision sensor with a cleaning robot to achieve autonomous pig house cleaning. In Decision and Control, 2005 and 2005 European Control Conference. CDC-ECC’05. 44th IEEE Conference on 8331–8336 (IEEE, 2005). Bormann, R., Fischer, J., Arbeiter, G., Weisshardt, F. & Verl, A. A visual dirt detection system for mobile service robots. In ROBOTIK 2012; 7th German Conference on Robotics 1–6 (2012). Bormann, R., Weisshardt, F., Arbeiter, G. & Fischer, J. Autonomous dirt detection for cleaning in office environments. In 2013 IEEE International Conference on Robotics and Automation 1260–1267 (2013). Milinda, H.G.T. & Madhusanka, B.G.D.A. Mud and dirt separation method for floor cleaning robot. In 2017 Moratuwa Engineering Research Conference (MERCon) 316–320 (2017). Lee, H. & Banerjee, A. Intelligent scheduling and motion control for household vacuum cleaning robot system using simulation based optimization. In 2015 Winter Simulation Conference (WSC) 1163–1171 (2015). Grünauer, A., Halmetschlager-Funek, G., Prankl, J. & Vincze, M. The power of gmms: Unsupervised dirt spot detection for industrial floor cleaning robots. In (eds. Gao, Y. et al.) Towards Autonomous Robotic Systems 436–449 (Springer International Publishing, 2017). Martínez, D., Alenyà, G. & Torras, C. Planning robot manipulation to clean planar surfaces. In Engineering Applications of Artificial Intelligence39 23–32. https://doi.org/10.1016/j.engappai.2014.11.004 (2015). Article Google Scholar Park, J., Chen, J., Cho, Y. K., Kang, D. Y. & Son, B. J. Cnn-based person detection using infrared images for night-time intrusion warning systems. Sensors20, 34. https://doi.org/10.3390/s20010034 (2020). ADSArticle Google Scholar Gomaa, A., Abdelwahab, M. M., Abo-Zahhad, M., Minematsu, T. & Taniguchi, R.-I. Robust vehicle detection and counting algorithm employing a convolution neural network and optical flow. Sensors19, 4588. https://doi.org/10.3390/s19204588 (2019). ADSArticlePubMed Central Google Scholar Fulton, M., Hong, J., Islam, M.J. & Sattar, J. In Robotic Detection of Marine Litter Using Deep Visual Detection Models. arXiv:1804.01079 (2018). Rad, M.S. et al. A computer vision system to localize and classify wastes on the streets. In ICVS (2017). Zhihong, C., Hebin, Z., Yanbo, W., Binyan, L. & Yu, L. A vision-based robotic grasping system using deep learning for garbage sorting. In Control Conference (CCC), 2017 36th Chinese 11223–11226 (IEEE, 2017). Cauli, N. et al. Autonomous table-cleaning from kinesthetic demonstrations using deep learning. In 2018 Joint IEEE 8th International Conference on Development and Learning and Epigenetic Robotics (ICDL-EpiRob) 26–32 (2018). Farooq, A., Farooq, F. & Le, A. V. Human action recognition via depth maps body parts of action. TIIS12, 2327–2347 (2018). Google Scholar Lakshmanan, A. K. et al. Complete coverage path planning using reinforcement learning for tetromino based cleaning and maintenance robot. Autom. Constr.112, 103078 (2020). Article Google Scholar Dijkstra, E. W. A note on two problems in connexion with graphs. Numer. Math.1, 269–271. https://doi.org/10.1007/BF01386390 (1959). MathSciNetArticleMATH Google Scholar Hart, P. E., Nilsson, N. J. & Raphael, B. A formal basis for the heuristic determination of minimum cost paths. IEEE Trans. Syst. Sci. Cybern.4, 100–107. https://doi.org/10.1109/TSSC.1968.300136 (1968). Article Google Scholar Stentz, A. Optimal and efficient path planning for partially-known environments. In Proceedings of the International Conference on Robotics and Automation 3310–3317. (1993). Koenig, S. & Likhachev, M. Fast replanning for navigation in unknown terrain. IEEE Trans. Robot.21, 354–363. https://doi.org/10.1109/TRO.2004.838026 (2005). Article Google Scholar Nazarahari, M., Khanmirza, E. & Doostie, S. Multi-objective multi-robot path planning in continuous environment using an enhanced genetic algorithm. Expert Syst. Appl.115, 106–120. https://doi.org/10.1016/j.eswa.2018.08.008 (2019). Article Google Scholar Cheng, K. P., Mohan, R. E., Nhan, N. H. K. & Le, A. V. Multi-objective genetic algorithm-based autonomous path planning for hinged-tetro reconfigurable tiling robot. IEEE Access8, 121267–121284. https://doi.org/10.1109/ACCESS.2020.3006579 (2020). Article Google Scholar Patle, B. K., Parhi, D. R. K., Jagadeesh, A. & KumarKashyap, S. Matrix-binary codes based genetic algorithm for path planning of mobile robot. Comput. Electr. Eng.67, 708–728. https://doi.org/10.1016/j.compeleceng.2017.12.011 (2018). Article Google Scholar Thabit, S. & Mohades, A. Multi-robot path planning based on multi-objective particle swarm optimization. IEEE Access7, 2138–2147. https://doi.org/10.1109/ACCESS.2018.2886245 (2018). Article Google Scholar Das, P. K., Behera, H. S. & Panigrahi, B. K. A hybridization of an improved particle swarm optimization and gravitational search algorithm for multi-robot path planning. Swarm Evol. Comput.28, 14–28. https://doi.org/10.1016/j.swevo.2015.10.011 (2016). Article Google Scholar PortaGarcia, M., OscarMontiel, Castillo, O., Sepúlveda, R. & Melin, P. Path planning for autonomous mobile robot navigation with ant colony optimization and fuzzy cost function evaluation. Appl. Soft Comput.9, 1102–1110. https://doi.org/10.1016/j.asoc.2009.02.014 (2009). Article Google Scholar Zeng, M.-R., Xi, L. & Xiao, A.-M. The free step length ant colony algorithm in mobile robot path planning. Adv. Robot.30, 1509–1514. https://doi.org/10.1080/01691864.2016.1240627 (2016). Article Google Scholar Clark, M. C. Probabilistic road map sampling strategies for multi-robot motion planning. Robot. Auton. Syst.53, 244–264. https://doi.org/10.1016/j.robot.2005.09.002 (2005). Article Google Scholar Niewola, A. & Podsedkowski, L. L* algorithm-a linear computational complexity graph searching algorithm for path planning. J. Intell. Robot. Syst.91, 425–444. https://doi.org/10.1007/s10846-017-0748-6 (2018). Article Google Scholar Karaman, S. & Frazzoli, E. Sampling-based algorithms for optimal motion planning. Int. J. Robot. Res.30, 846–894. https://doi.org/10.1177/0278364911406761 (2011). ArticleMATH Google Scholar Qureshi, A. H. & Ayaz, Y. Intelligent bidirectional rapidly-exploring random trees for optimal motion planning in complex cluttered environments. Robot. Auton. Syst.68, 1–11. https://doi.org/10.1016/j.robot.2015.02.007 (2015). Article Google Scholar Li, Y., Chen, H., Er, M. J. & Wang, X. Coverage path planning for uavs based on enhanced exact cellular decomposition method. Mechatronics21, 876–885. https://doi.org/10.1016/j.mechatronics.2010.10.009 (2011). Article Google Scholar Candeloro, M., Lekkas, A. M. & Sørensen, J. A. A voronoi-diagram-based dynamic path-planning system for underactuated marine vessels. Control Eng. Pract.61, 41–54. https://doi.org/10.1016/j.conengprac.2017.01.007 (2017). Article Google Scholar Bewley, A., Ge, Z., Ott, L., Ramos, F. & Upcroft, B. Simple online and realtime tracking. In 2016 IEEE International Conference on Image Processing (ICIP) 3464–3468 (2016). Tieleman, T. & Hinton, G. Lecture 6.5-rmsprop, coursera: Neural networks for machine learning. University of Toronto, Technical Report (2012). Le, A. V., Jung, S.-W. & Won, C. S. Directional joint bilateral filter for depth images. Sensors14, 11362–11378 (2014). ADSArticle Google Scholar Bradski, G. The OpenCV Library. In Dr. Dobb’s Journal of Software Tools (2000). Le, A. V. & Choi, J. Robust tracking occluded human in group by perception sensors network system. J. Intell. Robot. Syst.90, 349–361 (2018). Article Google Scholar Malandraki, C. & Dial, R. B. A restricted dynamic programming heuristic algorithm for the time dependent traveling salesman problem. Eur. J. Oper. Res.90, 45–55 (1996). Article Google Scholar Dorigo, M. & Di Caro, G. Ant colony optimization: A new meta-heuristic. In Proceedings of the 1999 congress on evolutionary computation-CEC99 (Cat. No. 99TH8406), vol. 2, 1470–1477 (IEEE, 1999). Le, A. V., Nhan, N. H. K. & Mohan, R. E. Evolutionary algorithm-based complete coverage path planning for tetriamond tiling robots. Sensors20, 445 (2020). ADSArticle Google Scholar Targ, S., Almeida, D. & Lyman, K. Resnet in resnet: Generalizing residual architectures. arXiv:1603.08029 (2016). Szegedy, C., Ioffe, S., Vanhoucke, V. & Alemi, A. Inception-v4, inception-resnet and the impact of residual connections on learning. arXiv:1602.07261 (2016). Quigley, M. et al. Ros: An open-source robot operating system. In ICRA workshop on open source software, vol. 3, 5 (Kobe, Japan, 2009). González, J. et al. Mobile robot localization based on ultra-wide-band ranging: A particle filter approach. Robot. Auton. Syst.57, 496–507 (2009). Article Google Scholar Download references This research is supported by the National Robotics Programme under its Robotics Enabling Capabilities and Technologies (Funding Agency Project No. 192 25 00051), National Robotics Programme under its Robot Domain Specific (Funding Agency Project No. 192 22 00058), National Robotics Programme under its Robotics Domain Specific (Funding Agency Project No. 192 22 00108), and administered by the Agency for Science, Technology and Research. ROAR Lab, Engineering Product Development, Singapore University of Technology and Design, Singapore, 487372, Singapore Balakrishnan Ramalingam, Anh Vu Le, Rajesh Elara Mohan & Sathian Pookkuttath School of Electrical and Electronics Engineering, Nanyang Technological University, Singapore, 639798, Singapore Zhiping Lin & Zhenyu Weng You can also search for this author in PubMedGoogle Scholar You can also search for this author in PubMedGoogle Scholar You can also search for this author in PubMedGoogle Scholar You can also search for this author in PubMedGoogle Scholar You can also search for this author in PubMedGoogle Scholar You can also search for this author in PubMedGoogle Scholar Conceptualization, R.E.M.; Methodology, R.E.M, Z.L.; Software, B.R, A.L., S.P., Z.W; Validation, R.E.M, Z.L.; Formal analysis, R.E.M, Z.L, B.R., S.P.; Investigation, B.R., A.L.; Resources, M.R.E.; Data curation, S.P., Z.W., Z.L; Writing—original draft, B.R., A.L , Z.W; Writing—review & editing, B.R., Z.W, Z.L; Visualization, S.P.; Supervision, M.R.E, Z.L; Project administration, M.R.E.; Funding acquisition, M.R.E. All authors have read and agreed to the published version of the manuscript. Correspondence to Balakrishnan Ramalingam. The authors declare no competing interests Springer Nature remains neutral with regard to jurisdictional claims in published maps and institutional affiliations. Open Access This article is licensed under a Creative Commons Attribution 4.0 International License, which permits use, sharing, adaptation, distribution and reproduction in any medium or format, as long as you give appropriate credit to the original author(s) and the source, provide a link to the Creative Commons licence, and indicate if changes were made. The images or other third party material in this article are included in the article’s Creative Commons licence, unless indicated otherwise in a credit line to the material. If material is not included in the article’s Creative Commons licence and your intended use is not permitted by statutory regulation or exceeds the permitted use, you will need to obtain permission directly from the copyright holder. To view a copy of this licence, visit http://creativecommons.org/licenses/by/4.0/. Reprints and Permissions Ramalingam, B., Le, A.V., Lin, Z. et al. Optimal selective floor cleaning using deep learning algorithms and reconfigurable robot hTetro. Sci Rep12, 15938 (2022). https://doi.org/10.1038/s41598-022-19249-7 Download citation Received: Accepted: Published: DOI: https://doi.org/10.1038/s41598-022-19249-7 Anyone you share the following link with will be able to read this content: Sorry, a shareable link is not currently available for this article.
Subscription Offers Give a Gift Subscribe John Payne Collier died on 17 September 1883, after a lifetime of creating deliberate fictions, falsehoods and forgeries.
‘An inquiry into the genuineness of the manuscript corrections in Mr. J. Payne Collier’s annotated Shakspere, folio, 1632: and of certain Shaksperian documents likewise published by Mr. Collier’, by N.E.S.A. Hamilton, 1860. Special Collections, University of Delaware Library.
September 24, 2022Stephen Clark Live coverage of the countdown and launch of a Delta 4-Heavy rocket with the classified NROL-91 payload for the National Reconnaissance Office. Text updates will appear automatically below. Follow us on Twitter. United Launch Alliance’s live launch broadcast begins at 2:33 p.m. PDT (5:33 p.m. EDT; 2133 GMT) on Saturday, Sept. 24.
Advertisement Parasites & Vectorsvolume 15, Article number: 336 (2022) Cite this article 1 Altmetric Metrics details Mathematical modelling of host-parasite systems has seen tremendous developments and broad applications in theoretical and applied ecology. The current study focuses on the infection dynamics of a gyrodactylid-fish system. Previous experimental studies have explored the infrapopulation dynamics of co-infecting ectoparasites, Gyrodactylus turnbulli and G. bullatarudis, on their fish host, Poecilia reticulata, but questions remain about parasite microhabitat preferences, host survival and parasite virulence over time. Here, we use more advanced statistics and a sophisticated mathematical model to investigate these questions based on empirical data to add to our understanding of this gyrodactylid-fish system. A rank-based multivariate Kruskal-Wallis test coupled with its post-hoc tests and graphical summaries were used to investigate the spatial and temporal parasite distribution of different gyrodactylid strains across different host populations. By adapting a multi-state Markov model that extends the standard survival models, we improved previous estimates of survival probabilities. Finally, we quantified parasite virulence of three different strains as a function of host mortality and recovery across different fish stocks and sexes. We confirmed that the captive-bred G. turnbulli and wild G. bullatarudis strains preferred the caudal and rostral regions respectively across different fish stocks; however, the wild G. turnbulli strain changed microhabitat preference over time, indicating microhabitat preference of gyrodactylids is host and time dependent. The average time of host infection before recovery or death was between 6 and 14 days. For this gyrodactylid-fish system, a longer period of host infection led to a higher chance of host recovery. Parasite-related mortalities are host, sex and time dependent, whereas fish size is confirmed to be the key determinant of host recovery. From existing empirical data, we provided new insights into the gyrodactylid-fish system. This study could inform the modelling of other host-parasite interactions where the entire infection history of the host is of interest by adapting multi-state Markov models. Such models are under-utilised in parasitological studies and could be expanded to estimate relevant epidemiological traits concerning parasite virulence and host survival. In the field of theoretical and applied ecology, mathematical modelling of host-parasite systems has seen tremendous advancement and applicability [1,2,3,4]. Mathematical models provide a logical framework for developing, testing and evaluating ecological hypotheses and biological systems. These models can be categorised as individual-based models (IBMs), population-based models (PBMs) or hybrid models (i.e., integration of IBMs and PBMs) [5]. IBMs strictly model each individual by tracking the state of each member of the population, whereas PBMs track the total number of individuals in each state. Common modelling setbacks often lie with the models’ underlying assumptions being too simple or too complex [6]. For instance, many traditional ecological or epidemiological models (e.g., logistic, Lotka-Volterra predator-prey and compartmental models) assume that all individuals (within a subgroup) are identical and can be lumped together to represent the population size (as a single state variable) [7, 8]. This population lumpability means that all details regarding individual physiological and behavioural traits (determined by their specific genetic, age structure and other environmental factors) are lost. For spatially dependent systems, individuals typically affect other organisms within their spatial-temporal neighbourhood [9, 10]. Nevertheless, the data-generating processes that characterise parasite aggregation in the standard statistical frameworks are mostly not explicitly described or further explored [7]. Consequently, many studies have been conducted to bridge these modelling gaps associated with PBMs by adopting IBMs through computer simulations [11]. Incorporating evidence from the individual level to investigate processes at the population (e.g., during survival analysis), community and ecosystem levels can also improve PBMs (through hybrid models by leveraging the respective advantages of IBMs and PBMs) [12]. Through survival analysis, an individual’s infection history can be modelled as a two-stage process, with the simplest transition being from “alive” to “dead” state [13]. In such instances, we often adopt the standard logistic regression or Cox proportional-hazards regression to investigate risk factors of host mortality and to estimate hazard rates, while the non-parametric Kaplan-Meier method is used to estimate survival curves from censored data [14]. However, in most longitudinal studies, the “alive” state could further be divided into two or more intermediate (transient) phases, each corresponding to a different stage of an infection [15]. Multi-state models (MSMs) allow for time-to-event longitudinal data analysis in which surviving individuals may have different health outcomes over time. MSMs can be considered a type of hybrid model since they model several events in a given population while capturing population heterogeneity based on each individual’s infection history. A change of (infection or disease) state is considered a transition or an event. Estimating progression rates, transition probabilities, the mean sojourn time in a given state and analysing the effects of individual risk factors, survival rates and prognostic forecasting are all areas of interest under multi-state modelling [16]. For biomedical applications, clinical symptoms (such as bleeding episodes), biological markers (e.g. CD4 cell counts or serum immunoglobulin levels), scale of the disease (e.g. stages of cancer or HIV infection), or a non-fatal complication during infection progression (e.g. cancer recurrence) could all be used to classify states [16]. The states could be transient or absorbing if no other transitions could emerge from the state (e.g. after a death event). Particularly in medical settings, it is common that the exact time for some individuals to transition into an absorbing state (e.g. death) after the beginning of the study may be unknown or never quantified if occurring after the observation period. This leads to the issue of censoring in survival analysis (namely, right-censored, left-censored and interval-censored observational times), and the censoring effect must be included in multi-state modelling, especially when constructing the model’s likelihood function [16]. The complexity of an MSM in any time-to-event modelling problem depends on the number of states and all possible transitions. Hence, a more robust model (such as MSM) is useful to employ when studying host-parasite infection dynamics (including host survival and parasite virulence) to reflect the biological realism of the system under study and improve upon the estimation of risk parameters such as survival probabilities and hazard ratios [17]. Hence, multi-state models are considered a natural extension of the standard survival models [18, 19]. Andersen and Borgan [20] and Hoem et al. [21] previously reviewed Markov models, and Cox and Miller [22] broadly discussed multi-state models. In epidemiology, the states of the process could also be defined as disease outcomes such as healthy, exposed, infected, diseased with complications, or dead. The state structure (which is not unique) describes the states and the various transitions between them. For each possible transition, an MSM is specified entirely by its state structure (defined by the transition rate at which an event occurs over time) and the form of the hazard function for the respective transitions (given individuals’ characteristics or covariates). Moreover, an MSM can either be time homogeneous (if the transition intensities or rates of the Markov chain are invariant over time) or time inhomogeneous (in the case of time-varying transition rates). Also, the time-space can be either discrete or continuous. Other studies of infection diseases have employed discrete-time multi-state Markov models (e.g.,[23, 24]). Comprehensive and flexible software packages (e.g. msm and msSurv R packages) help modellers fit any proposed continuous-time multi-state Markov model (for a given biological system) based on panel or longitudinal data and well-defined transition intensities [25, 26]. In population demography, there are three broad areas for adopting MSMs [27]. The first approach is that this class of models can be used to generalise the basic life table to a more general nonhierarchical increment-decrement life table [28]. These linear models for homogeneous groups are developed using aggregate level data and are based on Markov chains. They are related to multi-state projection models, which result in asymptotic populations that are stable or temporarily stable. The second approach of MSMs (dubbed multi-state event-history models) employs event history analysis based on individual data to allow interactions between different processes and incorporate population heterogeneity [29]. This heterogeneity may be time dependent and vary according to origin or destination state. In the third approach (used for contextual and multilevel multiprocess models), both individual and aggregate measures are analysed simultaneously (in a hybrid manner). Contextual models are a straightforward extension of traditional modelling techniques, including aggregation, where the behaviours of individuals in the same context are considered independent [30]. Software like the aML package can handle fitting such models [31]. Multilevel multiprocess models are simultaneous equation systems that include multilevel hazard equations with correlated random effects (due to within-group dependence being introduced). One of the modern statistical softwares used for multilevel multiprocess modelling is gsem [32]. However, MSMs are rarely used for studying veterinary or wildlife host-parasite interactions. In the current study, for the first time, MSM is used to investigate the infection progression of two co-infecting gyrodactylids across different fish hosts. Gyrodactylids are common fish parasites [33]. Gyrodactylus salaris alone caused epidemics among farmed salmonids, which resulted in death of up to 86% of salmon in infected rivers [34, 35]. They are monogenean ectoparasites that are ubiquitous on teleosts [36]. Amongst the well-studied Trinidadian guppy populations, gyrodactylids are the dominant parasites ((ge 42%) prevalence, 3.3 mean intensity; [37]). The prevalence of Gyrodactylus species varies spatially across watercourses (lower, mid and upper courses of the rivers or lakes) and temporally among Trinidadian populations and between host sexes [38]. Gyrodactylus prevalence is higher in female guppies, but only in lower courses [38], predominately because of fish shoaling behaviour [39, 40]. The parasites have no specific transmission stage and transfer from fish to fish occurs during host contact. Their reproductive mode is similar to that of microparasites with replication occurring directly on the host (reviewed by [34]). Their hyperviviparous nature and short generation times ((<24) h at (25^circ hbox {C}); [41]) can cause population explosions with substantial spatial and temporal variation amongst different species (e.g. [42,43,44,45,46]). Many infect the skin and fins; others occur predominantly on the gills [44, 47]. Gyrodactylus turnbulli and G. bullatarudis, which both infect the guppy (Poecilia reticulata), niche partition with G. turnbulli occurring caudally [48] and G. bullatarudis rostrally [49]. According to Harris [48], as individual host infections with G. turnbulli progress, parasites migrate from the caudal fin and body to the pectoral, pelvic, dorsal and anal fins, a migration to potentially facilitate transmission. Gyrodactylids may also move to optimise feeding, reduce competition and avoid localised immune reactions [34, 50,51,52,53,54], the scorched earth hypothesis [46]. Although the respective caudal and rostral preferences of G. turnbulli and G. bullatarudis on the host are well reported (e.g. [48, 49]), consistency over time and across different fish stocks is not. Host survival following gyrodactylid infection was previously explored by Cable and van Oosterhout [45]. They showed that mortality of guppies differed significantly between fish stocks for each parasite strain. From their experimental study, guppies were categorised according to whether they: (i) fought off the infection, (ii) remained infected, or (iii) died while infected. The fate of these guppies was predominantly affected by fish size, such that smaller guppies were more likely to clear the infection, while larger fish either died or remained infected beyond the end of the study period [45]. Parasites and their hosts compete for survival. Such co-evolutionary interactions drive virulence originating from parasite pathogenesis and host defence [55]. Together, measures of host mortality, host resistance, host recovery, mutation, superinfection, host heterogeneity and mode of transmission all contribute to explain parasite virulence [55]. Significant heterogeneity in virulence exists between Gyrodactylus turnbulli and Gyrodactylus bullatarudis strains [45] based on host mortality, host resistance and host heterogeneity, with less emphasis on host recovery as a measure of virulence [45, 56]. Although the proportion of gyrodactylid parasite-induced causalities on different fish host has been reported (e.g. [53]), the virulence of the three gyrodactylid strains on different fish stocks has not been quantified over time while accounting for possible changes in host infection status before host mortality may occur. The current study focuses on the spatial and temporal infection dynamics of the gyrodactylid-fish system by providing new epidemiological insights with the help of a robust time-inhomogeneous MSM, and a rank-based multivariate Kruskal-Wallis test coupled with its post-hoc tests. The time-inhomogeneous MSM is considered to analyse longitudinal survival data (instead of its time-homogeneous version) since transition intensities may naturally differ across individuals or time-varying covariates. We examine gyrodactylid microhabitat preference of three parasite strains (two strains of Gyrodactylus turnbulli and one strain of G. bullatarudis) and how these preferences vary across three different fish stocks over time based on existing experimental data. The proposed MSM is developed to improve on previous estimates of survival probabilities given fish sex, fish size, fish stock and parasite strain. We further quantify and compare the virulence (measured by rate of host mortality and recovery) over time and estimate other relevant epidemiological parameters (mean time of host to remain infected and probability of infected host to either recover or die across the covariates). The data used here are from the experimental study of Cable and van Oosterhout [45], subsequently used as the basis of an agent-based model in van Oosterhout [53]. Briefly, cultures of three different Gyrodactylus strains were used to infect three different fish stocks: Ornamental Stock (OS), Lower Aripo River fish (LA) and Upper Aripo River fish (UA); 157 guppies in total, in a full factorial design to give nine different host-parasite combinations, with 13–22 replicates per combination. Two out of the three parasite strains were Gyrodactylus turnbulli, a laboratory-bred strain (Gt3) and a wild turnbulli strain obtained from guppies caught in the Lower Aripo River, Trinidad (Gt), whereas the third strain was G. bullatarudis, also a wild type obtained from hosts in the Lower Aripo River. Both male (68) and female (89) individually isolated guppies were used for the experiment and maintained under constant environmental conditions ((25pm 0.5 ,^circ)C; 12h light/12h dark regime). All tanks and containers were kept in a randomised block design to reduce common environmental effects. The fish considered in the experiment were naive and thus bred under parasite-free conditions. Each fish was then infected with two parasites at time 0, and parasites were counted every 48 h over a 17-day infection period. For each fish, the number of parasites was recorded across eight different body regions (tail fin, lower body, upper body, anal fin, dorsal fin, pelvic fins, pectoral fins and head). Survival data describing the various host infection statuses (remain infected, recovered from the infection or died) over time were extracted from the empirical data for the multi-state modelling. The number of surviving fish (with or without host infection loss) and dead fish across the nine different host-parasite groups over time from days 1 to 17 is tabulated in Appendix 1. All analyses were carried out using R version 3.6.3 [57]. Images of fish were produced in Gimp software version 2.10.12 [58] and outlined in R. Two graphical summaries of the data were produced. These are available in full in the Additional file 1: Fig. S1 and Additional file 2: Fig. S2, with examples given in Figs. 1 and 2. For the first summary (Fig. 1 and Additional file 1: Fig. S1), the shading represents the log mean intensity of parasites over surviving fish. The number of surviving fish for the nine different host-parasite groups (obtained from the fully crossed design of the three parasite strains and three different host populations) generally decreased (slowly) over time from days 1 to 17 (refer to Appendix 1). For the second graphical summary (Fig. 2 and Additional file 2: Fig. S2), the eight body regions of the fish were recategorized into four: tail, lower region (comprising of the lower body, anal fin, pelvic fins and dorsal fin), upper region (made up of the upper body and pectoral fins) and the head. This re-categorisation allowed us to visually and statistically assess any caudal-rostral preference of the three parasite strains on the three fish stocks more effectively over the study period because of low parasite numbers observed on the fish fins (anal fin, pelvic fins, dorsal fin and pectoral fin). The movement of three different gyrodactylid parasites species/strains (Gt3, Gt and Gb) across eight host body parts (tail, lower body, anal fin, pelvic fins, dorsal fin, upper body, pectoral fins, head) of different fish stocks (OS, LA and UA stocks) at four time points. The degree of blackness indicates higher mean intensity (on log scale) over surviving fish Mean intensities (with corresponding 95% confidence intervals) of three gyrodactylid strains (Gt3, Gt and Gb) at four main body regions (tail, lower region, upper region and head) across three fish stocks (OS, LA and UA stocks) over surviving fish and across time The multivariate Kruskal–Wallis test (MKW) is a multivariate extension of the distribution-free univariate Kruskal-Wallis test [59]. We used it to test the null hypothesis that distribution of parasite number at the four body regions (tail, lower region, upper region and head) is equal for the different host-parasite combinations at each observed time point. Let (Y_{ij}) be a vector of the number of parasites at the four body regions for the jth fish from the ith group (host-parasite combination), where (i=1,2,3,cdots ,9) and (j=1,2,3,cdots ,n_{i}). Let (R_{ij}) be the rank corresponding to (Y_{ij}) calculated element-wise (ties are assigned a mean rank) and ({bar{R}}_{i}=sum nolimits _{j=1}^{n_i}{frac{R_{ij}}{n_i}}) then (E({bar{R}}_{i})=m=frac{n+1}{2}) under (H_0); where (n=sum nolimits _{i=1}^{9}{n_i}) is the total number of fish ((n=157)), ({bar{R}}_{i}) is the mean rank for each ith group and ({n_i}) is the number of fish in group i. The vector (U_{i}=(bar{R}_{i1}-m,bar{R}_{i2}-m,bar{R}_{i3}-m,bar{R}_{i4}-m)^prime) denotes the average ranks for the ith group corrected for m for each variate (body regions). The pooled within-group covariance matrix is estimated as where (R_{ij}=(R_{ij1},R_{ij2},R_{ij3},R_{ij4})^{prime }) and (1=(1,1,1,1)^{prime }). The MKW test statistic (({mathcal {W}})), given as is approximately (asymptotically) chi-squared with (k(g-1)) degrees of freedom, where (k=4) and (g=9) [59]. After performing the MKW, the univariate Kruskal-Wallis test (UKW) was used to further compare the distribution of parasites at each of the four body regions for each parasite strain (Gt3, Gt and Gb) across the fish stocks (OS, LA and UA) at each time point (days 1 to 17). A Bonferroni-Dunn’s post-hoc test was finally applied for pairwise comparisons of the parasite distribution between the different parasite-fish combinations over time. The caudal-rostral preference of the three parasite strains on the three fish stocks was statistically inferred from these tests (testing the niche partition hypothesis of Gyrodactylus turnbulli and G. bullatarudis for preferences at the caudal and head regions, respectively). Individual fish after being infected can transition among three discrete host states—fish remains infected (state 1), fish alive with loss of infection (state 2) and fish dead (state 3)—over the observation period. Let ({X_i(t); t ge 0}) be the state of fish i over time. We suppose that ({X_i(t)}) is a time-inhomogeneous Markov chain with transition rate matrix (Q(t)={q_{rs}(t)}) for (r,s=1,2,3). For each (i=1,2, cdots , 157), we have observations (X_i=(X_{i0},X_{i1},cdots ,X_{i9})) at times (t_0=0), (t_1=1), (t_2=3), (cdots) and (t_9=17). The likelihood for the model parameters (theta ={q_{rs}(t)}) is given as where (L_i(theta |x_i)) is the likelihood contribution for each fish i obtained as product of state transition probabilities with (p_{x_{ij-1},x_{ij}}(t_{j-1},t_{j})=P{X_i(t_{j})=x_{ij}|X_i(t_{j-1})=x_{ij-1} }.) We assumed that once a fish had lost its infection (state 2) or died (state 3), it could not be reinfected because of the experimental design (move back to state 1) and thus the corresponding rates are 0. Hence, the transition rate matrix Q(t) for the multi-state model with the three discrete host states is given as where (q_{12}(t)>0) and (q_{13}(t)>0) are the rates at which an infected fish loses its infection and dies at time t respectively. Here, we modelled the rate matrix Q(t) as a piecewise constant function with change points (t_1,t_2,cdots ,t_{8}). For (t{in }[t_{j-1},t_j)), we write (Q(t)=Q_j). The transition probability matrix is The likelihood function for the model parameters is estimated using a maximum likelihood method, fitted using the msm package in R [60]. We examine how variables such as fish sex, fish size, fish stock and parasite strain may affect the transition rates Q(t). Let (z_i={z_{i1},z_{i2},z_{i3}, z_{i4}}) be the realized values of the covariates (fish sex, fish size, fish stock and parasite strain) for fish i. Then, the transition rate matrix entries (q_{rs}(t)) for (r, s= 1, 2, 3) and (t{in }[t_{j-1},t_j)) were taken as where ({q_{rsj}^{(0)}}) is baseline intensity; (beta _{rs}) is a parameter vector. The likelihood is then maximized over ({q_{rsj}^{(0)}}) and the regression coefficients (beta _{rs}), for (r=1) and (s=2,3). The hazard ratios (HR) corresponding to each covariate are (exp(beta _{rs})), for (r=1) and (s=2,3). The transition probabilities were estimated from (q_{rs}(t, z_i)) using Eq. 5. Given the four predictors (fish sex, fish size, fish stock and parasite strain) and two possible transitions from state 1 to either state 2 ((q_{12})) or state 3 ((q_{13})) in the proposed multi-state Markov model (defined by Eq. 6), there are (16^2) (or 256) possible variable permutations or models (which includes transitions independent of the underlying covariates). A systematic variable and model selection was carried out using both Akaike information criterion (AIC) and Bayesian information criterion (BIC) statistics (due to the relative advantages of the two model selection criteria), where all possible variable permutations or models were considered. The AIC statistic assesses the model’s goodness of fit while reducing the complexity of the underlying parameters, whereas the BIC statistics penalise adding more parameters or strongly penalise free parameters compared to the AIC statistic. According to Kuha [61], effective model selection can be achieved by using both AIC and BIC statistics, predominantly to identify models favoured by both criteria, although the study’s methodological design, the main research questions and the belief of a true model and its applicability to the study are crucial factors in determining whether to utilise the AIC or BIC [62]. The best model (among identified parsimonious or highly predictive models) was finally chosen based on a likelihood ratio test (LRT) at a 5% significance level. Detailed results on the variable selection for the multi-state model and its R codes (for reproducibility of results) can be found via the GitHub URL link: github.com/twumasiclement/Spatial-Temporal-Parasite-Dynamics. Let (T_1) be the time spent in state 1, given that the fish or the process is in state 1 at time 0. Then, the mean sojourn time in state 1 is given as where with and (E(S_j|S_jle t_j-t_{j-1})) is given by Eq. 11 according to Theorem 1. In Eq. 7, the probability that the process leaves in period j, denoted by (text {P(leave in period j)}), is computed such that with in accordance to Eq. 10 under Theorem 1. Let (S_j) be the time spent by infected fish during period j. Suppose that (S_j sim exp left( q_{12}(j,z_i)+q_{13}(j,z_i) right)) with probability density where (q_{12}(j,z_i)) and (q_{13}(j,z_i)) are the transition rates from state 1 to state 2 and 3, respectively, given the covariates (z_i) for fish i, such that Then, and For the mathematical proof to Theorem 1, see Appendix 2. From Theorem 1, it can be deduced that where Also, given the fish or process is in state 1, then the probability of moving to state 2 or 3 next is given as where for (s=2,3). We assume that (q_{12}(t,z_i)=q_{12}(15,z_i)) and (q_{13}(t,z_i)=q_{13}(15,z_i)) for (t ge 15). Fish heatmaps (Fig. 1 and Additional file 1: Fig. S1) depict variations in parasite distribution across eight body regions (caudal fin, lower body, upper body, anal fin, pelvic fin, dorsal fin, pectoral fin and head) over time for each gyrodactylid strain (Gt3, Gt and Gb) on the different fish stocks (OS, LA and UA). Gt3 showed a clear preference for the caudal fin and lower body, with higher mean intensities on OS and LA fish than on the UA stock from day 7 until the end of the infection period. By day 15, all the UA fish had lost the Gt3 infection. Similarly, Gt was more abundant on the tail and lower body until day 13, but switched to a head preference among only OS and LA populations on day 15. In contrast, Gb showed a clear rostral preference from day 7 onwards, a preference strongest in OS(ge)LA(ge)UA fish stocks until the end of the infection period. When comparing just four body regions of the fish (tail, lower region, upper region and head), the peak time of infection varied spatially across parasite strains and fish stocks (Table 1; Fig. 2). On day 15, higher mean intensities were recorded on the head for both Gt and Gb on OS fish stock. Also for Gb on the same fish stock, a higher number of parasites occurred on the head between days 9 and 17 compared to any other body region or host-parasite combinations (Fig. 2 and Additional file 2: Fig. S2). Parasite distributions varied at the four body regions across the nine host-parasite combinations (Fig. 2) from days 1 to 15 (MKW, (71.25{le }W{le }168.57), (df=32), (p<0.001)), but not on day 17 ((W=38.12), (df=32), (p=0.211)). Only the parasite distribution at the tail and head respectively differed significantly across the nine host-parasite combinations from days 1 to 5 and on day 9 ((ple 0.001)). However, parasite distribution differed significantly among groups on the lower body region on days 7 and 11 (UKW, ({17.12le }H{le }17.74), (df=8), (0.023{le }p{le }0.029)), tail on days 7 and 15 (({19.49le }H{le }24.93), (df=8), (0.002{le }p{le }0.012)) and head on days 7, 11 and 13 ((21.22{le }H{le }47.36), (df=8), (0.001<p{le }0.007)). From the Bonferroni-Dunn tests, there were significant pairwise differences in parasite distribution at the tail between all Gb groups (Gb-OS, Gb-LA and Gb-UA) and G. turnbulli strains on the fish stocks (with the exception of Gt3 on OS) during day 1 of infection ((0.001< ple)0.016). However, there was no significant difference in parasite distribution of the G. turnbulli strains at the tail across the three fish stocks over time; with the exception of days 3 and 15, between Gt3-OS and Gt-LA groups ((p=0.019)) as well as between Gt3-LA and Gt3-UA groups ((p=0.037)). On days 3 and 5, parasite distribution at the tail was significantly different ((0.001<ple)0.036) between all Gb groups and Gt groups with the exception Gt-OS for day 3 and Gt-UA for day 5. Parasite distribution at the tail on day 7 was significantly different between Gb-UA and Gt groups (Gt-OS and Gt-UA), whilst a significant difference was found between Gb-UA and Gt groups (Gt-LA and Gt-UA). Nevertheless, there was no significant difference between groups of the G. turnbulli strains and G. bullatarudis from day 15 till the end of the infection period. Significant difference in parasite distribution on the lower region only occurred on day 7 between Gt-OS and Gb-UA groups ((p=0.039)) and on day 11 between Gb-UA and Gt-LA groups ((p=0.014)). Nonetheless, parasite distribution on the head was significantly different ((0.001<ple 0.013)) between each of the G. bullatarudis groups (Gb-OS and Gb-UA) and all the G. turnbulli groups on day 1. But from days 3 to 5, significant pairwise difference ((0.001<ple 0.046)) was found between all Gb groups and turnbulli strains for all fish stocks respectively at the head. However, apart from Gb-OS group that still showed significant difference with all G. turnbulli groups on day 7 ((0.001<ple 0.016)), Gb-LA and Gb-UA rather showed significance difference ((0.001<ple 0.037)) with Gt3-OS and Gt3-LA. Nevertheless, Gb on OS showed difference significantly ((0.001<ple 0.013)) on the head with Gt3 on OS and LA stocks as well as Gt on LA population during day 9, whereas two groups of Gb (on OS and LA stocks) had significant difference with only Gt3 on OS fish population during day 11 of the infection period. On day 13, there was significant difference in parasite distribution on the head between Gb and Gt on ornamental fish only. We used the time-inhomogeneous multi-state Markov model to examine the significant determinants of fish survival (fish sex, fish size, fish stock and parasite strain). The estimated hazard ratios (HR) corresponding to each significant predictor of the fitted model are summarized by Table 2. Figure 3 shows how the baseline transition rates from the infected state (state 1) to uninfected (state 2) and dead (state 3) states changed over the observed time intervals. Figure 4 shows that the fitted multi-state model gives a very good fit to the proportion of fish that will remain in each host infection status from the onset of infection to the end of the study period. Piecewise-constant plot of estimated baseline transition rates from infected host state to uninfected and dead states at different observed time intervals in the time-inhomogeneous multi-state Markov model Comparison between observed and expected proportions of fish that will remain in each host infection state from days 1 to 17 after the onset of gyrodactylid infection based on the fitted multi-state Markov model (mean absolute percentage error = 7.85%) The likelihood of infected fish fighting off their infection was significantly influenced by fish size ((hbox {HR}=0.87), 95% (hbox {C.I}=0.76)-0.99, (p=0.037)), such that larger fish are less likely to clear off their infection. Fish sex, fish stock and parasite strain did influence the likelihood of infected fish dying, but not parasite extinction. Infected male fish were 52% more likely to die compared to female fish ((hbox {HR}=1.52), 95% (hbox {C.I}=1.04)-2.22, (p=0.031)). The risk of death from the gyrodactylid infection among the OS fish ((hbox {HR}=0.24), 95% (hbox {C.I}=0.14)-0.39, (p<0.001)) was 76% less likely compared to UA fish stock. LA fish ((hbox {HR}=0.39), 95% (hbox {C.I}=0.25)-0.61, (p<0.001)) were 61% less likely to die from gyrodactylid infections relative to UA fish. Based on estimated hazard ratios, the rate of fish survival from the gyrodactylid infections was higher among OS stock, followed by LA stock and then UA stock. Fish infected by laboratory strain of G. turnbulli ((hbox {HR}=1.65), 95% (hbox {C.I}=1.03)-2.65, (p=0.037)) were 65% more likely to die compared to the wild strain. The wild G. bullatarudis strain ((hbox {HR}=1.64), 95% (hbox {C.I}=1.02)-2.62, (p=0.039)) was also 64% more likely to kill fish compared to the wild G. turnbulli strain. The estimates of the hazard ratios corresponding to Gt3 and Gb relative to wild G. turnbulli strain suggest that there is no significant difference in the likelihood of fish mortality between Gt3 and Gb strains. We quantified parasite virulence by estimating the rates of both host mortality (Fig. 5) and host recovery (Fig. 6) over time using the fitted multi-state Markov model. Predicted host mortality rates of parasite strains (Gt3, Gt and Gb) on the fish stocks (OS, LA and UA stocks) over time for both male and female fish respectively Predicted host recovery rates over time at different fish sizes (11, 14, 17, 20, 23 and 26 mm) We estimated the mean sojourn time in state 1 (the average amount of time fish can remain infected) and the probability of next transition from the infected state (state 1) to either recovery (state 2) or dead state (state 3) across all significant predictors (fish sex, fish size, fish stock and parasite strain) of the fitted multi-state Markov model. For any strain of gyrodactylid, large ornamental female fish remained infected longer than fish with any other attributes (Table 3). Fish infected with the wild G. turnbulli strain on average remained infected longer than fish infected with Gt3 or wild G. bullatarudis strains before either recovering or dying, irrespective of the fish size, stock and sex. The mean time for fish to remain infected with any parasite strain before fighting off their infection or dying was between 6 and 14 days. An infected fish had a higher probability of dying than recovering from the infection irrespective of the type of gyrodactylid infection, fish stock, sex and size (Table 4). Large male fish were more likely to die than small or medium-sized male or female fish of any size, whereas the chance of host recovery was higher among OS fish stock compared to the Trinidadian fish stocks. The fish infected with wild G. turnbulli strain had a greater probability of fighting off their infections than fish infected with either Gt3 or Gb strain. In this study, we built on previous studies of the infrapopulation dynamics of three different gyrodactylid strains (two strains of G. turnbulli and one strain of G. bullatarudis) among three different fish stocks (OS, LA and UA stocks) in relation to parasite habitat preference, host survival and parasite virulence (see [45, 48, 49, 56]). We have confirmed for the first time that the microhabitat preferences of the G. turnbulli (laboratory and wild type) and G. bullatarudis strains depend on the type of host and can change over time for the wild G. turnbulli strain (with the help of a multivariate ranked-based distribution-free test and associated post-hoc tests). With an extension to the traditional survival models, we have been able to include host recovery as another absorbing state, and fish sex was identified as a significant factor of host survival compared to previous study of this biological system [45]. We also estimated for the first time, the average duration that fish can remain infectious and the probability that infected fish will either recover or die from each of the three parasite strains across the three guppy populations, sexes and different fish sizes (small, medium and large sizes). The captive-inbred G. turnbulli strain preferred the tail of three different fish stocks (Ornamental, Lower Aripo River and Upper Aripo River stocks), whereas the wild G. turnbulli initially preferred the tail but then switched to the head. The wild Gyrodactylus bullatarudis consistently showed a rostral preference on all fish. The mean intensity of parasites was higher on OS and LA fish than UA stocks across all body regions over time, probably related to the higher mortality of the UA fish. Lower numbers of parasites on the pectoral, pelvic, dorsal and anal fins compared to the tail, lower body, upper body and head regions might be affected by fish being maintained in isolation or due to difference in the surface area of these body regions. Individual host isolation meant there was no opportunity for host-to-host transmission to occur via the fins (as suggested by [48]). Thus, the parasites might be making a behavioural decision to enhance their fitness in response to the absence of alternative hosts and or reduce competition at small-sized body regions over time. The peak time to infection varied spatially across parasite strains and fish stocks. Such variation likely represents a trade-off between successful parasite exploitation and the host’s localised immune response (reviewed by [34]). Parasite distribution on infected hosts could also be driven by multiple abiotic and biotic factors [50,51,52, 54]. The fitted multi-state model revealed that fish sex, fish stock and parasite strain influenced fish mortality. LA and OS fish stocks survived for longer than UA fish. For this gyrodactylid-fish system, the current study revealed that a longer period of host infection leads to a higher chance of host recovery and a smaller chance of host mortality. The OS guppy population was infectious longer than the Trinidadian fish stocks (LA and UA fish) based on the estimated average duration of infection. However, the OS guppies had a higher chance of host recovery compared to the LA and UA fish stocks, potentially due to superior innate immune defences or immunocompetence towards single-species infections (as revealed by [63, 64]). The LA fish consistently had better parasite resistance than the UA stock across fish sex, parasite strain and different host sizes. Larger fish were infectious over a longer period than small or medium-sized fish, whereas female fish from all three guppy populations experienced a longer duration of infection than male fish. Fish infected by the wild strain of G. turnbulli on average remained infected longer with a higher probability of host recovery among all fish stocks and sexes. As in the previous study, the laboratory strain of G. turnbulli and wild strain of G. bullatarudis were more likely to cause fish mortality than the wild strain of G. turnbulli, but we found that infected male fish were twice as likely to die relative to female fish. The main reason for this new finding of fish sex as a significant determinant of host mortality is the use of a multi-state model that is able to incorporate host mortality and recovery simultaneously. Other parasite-fish studies have identified fish sex as a significant factor of host mortality [65]. Only fish size significantly influenced the rate of infection loss, namely larger fish acquired more parasites as infections progressed resulting in low parasite extinction compared to smaller fish [53]. Nevertheless, it was found that the chance of host mortality was more likely to occur than host recovery irrespective of host size. Parasite virulence, described in terms of host mortality and recovery, was significantly time dependent and generally increased towards the end of the infection period. Previously, Gt3 was identified as causing most host deaths, followed by G. bullatarudis and then the wild G. turnbulli, but their respective host mortality rates were not quantified, nor did we previously consider how this changed over time, nor the effect of the different fish stocks [45]. Here, we found no significant difference in host mortality rates between Gt3 and Gb parasite strains over time. Male fish from the three different guppy populations (OS, LA and UA stocks) consistently had a higher rate of host mortality than female fish stocks over time. This could be explained by the fact that the female fish are infectious longer than the male fish as revealed by the estimated mean sojourn time of infection; thus, the female host populations likely develop innate or adaptive host immunity faster than the male fish stocks over time. The current study could inform the modelling and survival analyses of other biological systems where the entire infection history of an individual (or host) is of interest. Multi-state Markov models provide a robust approach to modelling almost any kind of longitudinal time-to-event data [20]. For multi-state processes that are misclassified or can only be viewed through a noisy marker, hidden Markov models can be implemented [25]. There is more extensive literature on different classes of multi-state Markov models and Markov extension models with specific applications to the modelling of fertility, infectious diseases, competing risks, disability, recurrent events, twin survival and alternating events (reviewed by [15]). However, they have been underused in most parasitological fields. In the current multi-state Markov model, we could not include spatial information and other relevant information about parasite fecundity, age group (young or old parasite), parasite mortality, parasite mobility and host immune response. A more sophisticated (individual-based) stochastic simulation model would be needed to include these data to further understand the gyrodactylid-fish system. Future studies will examine host-to-host transmission to holistically understand the spread of gyrodactylid parasites and the host-parasite interactions among different populations of fish. In summary, we identified host-parasite strain-specific microhabitat preferences, discovered determinants of host survival and quantified host-specific parasite virulence based on both host mortality and recovery. The multi-state model was designed so that fish could not be reinfected after infection to match the experimental design, but this could be modified in future studies to include transmission. The multi-state Markov model and the rank-based multivariate Kruskal-Wallis test can be extended and adapted for studying other host-parasite interactions. The datasets generated and/or analysed during the current study are available from the corresponding author on reasonable request. The R codes used for all statistical analyses have been made publicly available for reproducibility of results via the URL link: https://github.com/twumasiclement/Spatial-Temporal-Parasite-Dynamics. Akaike information criterion Bayesian information criterion Wild Gyrodactylus bullatarudis strain Wild Gyrodactylus turnbulli strain Laboratory-bred Gyrodactylus turnbulli strain Hazard ratio Individual-based model Lower Aripo River fish Likelihood ratio test Multi-state model Multivariate Kruskal-Wallis test Ornamental stock Population-based model Univariate Kruskal–Wallis test Upper Aripo River fish Milner F, Patton C. A new approach to mathematical modeling of host-parasite systems. Comput Math Appl. 1999;37(2):93–110. Article Google Scholar Berec L. Techniques of spatially explicit individual-based models: construction, simulation, and mean-field analysis. Ecol Model. 2002;150(1–2):55–81. Article Google Scholar Adda P, Dimi JL, Iggidir A, Kamgang JC, Sallet G, Tewa JJ. General models of host-parasite systems. Global analysis. Discrete Contin Dyn Syst B. 2007;8(1):1. Google Scholar Edessa GK, Koya PR. Modeling and stability analysis of host-parasite population dynamics. Math Model Appl. 2020;5:28. Google Scholar Gallagher S, Baltimore J. Comparing compartment and agent-based models. In: Eddy WF, editor. Joint statistical meeting, Baltimore; 2017. p. 1–21. DeAngelis DL. Individual-based models and approaches in ecology: populations, communities and ecosystems. Boca Raton: CRC Press; 2018. Book Google Scholar Gourbière S, Morand S, Waxman D. Fundamental factors determining the nature of parasite aggregation in hosts. PLoS ONE. 2015;10(2): e0116893. PubMedPubMed CentralArticle Google Scholar Wilson K, Grenfell BT, Shaw DJ. Analysis of aggregated parasite distributions: a comparison of methods. Funct Ecol. 2006;10(5):592. Article Google Scholar Caswell H. Matrix population models, vol. 1. Massachusetts: Sinauer Sunderland; 2000. Google Scholar Metz JA, Diekmann O. The dynamics of physiologically structured populations, vol. 68. Berlin: Springer; 2014. Google Scholar Huston M, DeAngelis D, Post W. New computer models unify ecological theory: computer simulations show that many ecological patterns can be explained by interactions among individual organisms. Bioscience. 1988;38(10):682–91. Article Google Scholar Wallentin G, Neuwirth C. Dynamic hybrid modelling: switching between AB and SD designs of a predator-prey model. Ecol Model. 2017;345:165–75. Article Google Scholar Abbott RD. Logistic regression in survival analysis. Am J Epidemiol. 1985;121(3):465–71. CASPubMedArticle Google Scholar Efron B. Logistic regression, survival analysis, and the Kaplan-Meier curve. J Am Stat Assoc. 1988;83(402):414–25. Article Google Scholar Hougaard P. Multi-state models: a review. Lifetime Data Anal. 1999;5(3):239–64. CASPubMedArticle Google Scholar Meira-Machado L, de Uña-Álvarez J, Cadarso-Suárez C, Andersen PK. Multi-state models for the analysis of time-to-event data. Stat Methods Med Res. 2009;18(2):195–222. PubMedArticle Google Scholar Berry SD, Ngo L, Samelson EJ, Kiel DP. Competing risk of death: an important consideration in studies of older adults. J Am Geriatr Soc. 2010;58(4):783–7. PubMedPubMed CentralArticle Google Scholar Marshall G, Jones RH. Multi-state models and diabetic retinopathy. Stat Med. 1995;14(18):1975–83. CASPubMedArticle Google Scholar Manzini G, Ettrich TJ, Kremer M, Kornmann M, Henne-Bruns D, Eikema DA, et al. Advantages of a multi-state approach in surgical research: how intermediate events and risk factor profile affect the prognosis of a patient with locally advanced rectal cancer. BMC Med Res Methodol. 2018;18(1):23. CASPubMedPubMed CentralArticle Google Scholar Andersen PK, Borgan Ø. Counting process models for life history data: a review. Preprint series Statistical Research Report. http://urn nb no/URN: NBN: no-23420. 1984;p. 1–104. Hoem JM, Keiding N, Kulokari H, Natvig B, Barndorff-Nielsen O, Hilden J. The statistical theory of demographic rates: a review of current developments [with discussion and reply]. Scand J Stat. 1976;p. 169–185. Cox DR, Miller HD. The theory of stochastic processes. Milton Park: Routledge; 2017. Book Google Scholar Li Y, Cui L, Lin C. Modeling and analysis for multi-state systems with discrete-time Markov regime-switching. Reliabil Eng Syst Saf. 2017;166:41–9. Article Google Scholar Chakladar S, Liao R, Landau W, Gamalo M, Wang Y. Discrete time multistate model with regime switching for modeling COVID-19 disease progression and clinical outcomes. Stat Biopharm Res. 2022;14(1):52–66. Article Google Scholar Jackson CH. Multi-state models for panel data: the msm package for R. J Stat Softw. 2011;38(8):1–29. Article Google Scholar Ferguson N, Datta S, Brock G. msSurv: an R package for nonparametric estimation of multistate models. J Stat Softw. 2012;50:1–24. Article Google Scholar Courgeau D. Multistate transition models in demography. In: Smelser NJ, Baltes PB, editors. International Encyclopedia of the Social and Behavioral Sciences. Oxford: Pergamon Press; 2001. p. 10210–10214. https://www.sciencedirect.com/science/article/pii/B0080430767021021. Land KC, Rogers A. Multidimensional mathematical demography: an overview. Multidimension Math Demogr. 1982;p. 1–4. Courgeau D, Lelièvre E, Lelièvre É. Event history analysis in demography. Oxford: Clarendon Press; 1992. Google Scholar Lelievre E, Bonvalet C, Bry X. Event history analysis of groups. The findings of an on-going research project. Population: an English selection. 1998;p. 11–38. Lillard LA, Panis CW. aML multilevel multiprocess statistical software, version 2.0. EconWare, Los Angeles, California. 2003. http://www.applied-ml.com. Bartus T. Multilevel multiprocess modeling with GSEM. Stand Genomic Sci. 2017;17(2):442–61. Google Scholar Shinn A, Pratoomyot J, Bron J, Paladini G, Brooker E, Brooker A. Economic impacts of aquatic parasites on global finfish production. Glob Aquacult Advocate. 2015;2015:58–61. Google Scholar Bakke TA, Cable J, Harris PD. The biology of gyrodactylid monogeneans: the “Russian-Doll Killers’’. Adv Parasitol. 2007;64:161–460. CASPubMedArticle Google Scholar Leung TLF, Bates AE. More rapid and severe disease outbreaks for aquaculture at the tropics: implications for food security. J Appl Ecol. 2013;50(1):215–22. Article Google Scholar Harris PD, Shinn A, Cable J, Bakke TA. Nominal species of the genus Gyrodactylus von Nordmann 1832 (Monogenea: Gyrodactylidae), with a list of principal host species. Syst Parasitol. 2004;59(1):1–27. CASPubMedArticle Google Scholar Cable J, Archard GA, Mohammed RS, McMullan M, Stephenson JF, Hansen H, et al. Can parasites use predators to spread between primary hosts? Parasitology. 2013;140(9):1138–43. PubMedArticle Google Scholar Stephenson JF, Van Oosterhout C, Mohammed RS, Cable J. Parasites of Trinidadian guppies: evidence for sex-and age-specific trait-mediated indirect effects of predators. Ecology. 2015;96(2):489–98. PubMedArticle Google Scholar Griffiths SW, Magurran AE. Sex and schooling behaviour in the Trinidadian guppy. Anim Behav. 1998;56(3):689–93. CASPubMedArticle Google Scholar Croft DP, Edenbrow M, Darden SK, Ramnarine IW, van Oosterhout C, Cable J. Effect of gyrodactylid ectoparasites on host behaviour and social network structure in guppies Poecilia reticulata. Behav Ecol Sociobiol. 2011;65(12):2219–27. Article Google Scholar Scott ME. Reproductive potential of Gyrodactylus bullatarudis (Monogenea) on guppies (Poecilia reticulata). Parasitology. 1982;85(2):217–36. Article Google Scholar Malmberg G, et al. The excretory systems and the marginal hooks as a basis for the systematics of Gyrodactylus (Trematoda, Monogenea). Arkiv for Zoologi. 1970;23(1/2):1–235. Google Scholar Llewellyn J. The biology of Isancistrum subulatae n. sp., a monogenean parasitic on the squid, Alloteuthis subulata, at Plymouth. J Mar Biol Assoc UK. 1984;64(2):285–302. Article Google Scholar Harris PD. Interactions between reproduction and population biology in gyrodactylid monogeneans: a review. B Fr Peche Piscic. 1993;1:47–65. Article Google Scholar Cable J, van Oosterhout C. The impact of parasites on the life history evolution of guppies (Poecilia reticulata): the effects of host size on parasite virulence. Int J Parasitol. 2007;37(13):1449–58. CASPubMedArticle Google Scholar Rubio-Godoy M, Muñoz-Córdova G, Garduño-Lugo M, Salazar-Ulloa M, Mercado-Vidal G. Microhabitat use, not temperature, regulates intensity of Gyrodactylus cichlidarum long-term infection on farmed tilapia-Are parasites evading competition or immunity? Vet Parasitol. 2012;183(3–4):305–16. PubMedArticle Google Scholar Ogawa K. A monogenean parasite Gyrodactylus masu sp. n. (Monogenea: Gyrodactylidae) of salmonid fish in Japan. Nippon Suisan Gakkaishi. 1986;52(6):947–950. http://joi.jlc.jst.go.jp/JST.Journalarchive/suisan1932/52.947?from=CrossRef. Harris PD. Changes in the site specificity of Gyrodactylus turnbulli Harris, 1986 (Monogenea) during infections of individual guppies (Poecilia reticulata Peters, 1859). Can J Zool. 1988;66(12):2854–2857. http://www.nrcresearchpress.com/doi/10.1139/z88-414. Harris PD, Lyles AM. Infections of Gyrodactylus bullatarudis and Gyrodactylus turnbulli on guppies (Poecilia reticulata) in Trinidad. J Parasitol. 1992;p. 912–914. Richards G, Chubb J. Host response to initial and challenge infections, following treatment, of Gyrodactylus bullatarudis and G. turnbulli (Monogenea) on the guppy (Poecilia reticulata). Parasitol Res. 1996;82(3):242–7. CASPubMedArticle Google Scholar Hatcher MJ, Dick JT, Dunn AM. How parasites affect interactions between competitors and predators. Ecol Lett. 2006;9(11):1253–71. PubMedArticle Google Scholar Harvell CD, Mitchell CE, Ward JR, Altizer S, Dobson AP, Ostfeld RS, et al. Climate warming and disease risks for terrestrial and marine biota. Science. 2002;296(5576):2158–62. CASPubMedArticle Google Scholar van Oosterhout C, Potter R, Wright H, Cable J. Gyro-scope: an individual-based computer model to forecast gyrodactylid infections on fish hosts. Int J Parasitol. 2008;38(5):541–8. PubMedArticle Google Scholar Lu DB, Rudge JW, Wang TP, Donnelly CA, Fang GR, Webster JP. Transmission of Schistosoma japonicum in Marshland and hilly regions of China: Parasite population genetic and sibship structure. PLoS Negl Trop Dis. 2010;4(8). Mandal FB. Does virulence offer benefit to the parasite ? WebmedCentral Parasitol. 2011;2(10):1–9. Google Scholar Stephenson JF, Young KA, Fox J, Jokela J, Cable J, Perkins SE. Host heterogeneity affects both parasite transmission to and fitness on subsequent hosts. Phil Trans R Soc B Biol Sci. 2017;372(1719):1–10. Article Google Scholar R Core Team, et al.. Hurley C, editor. R: a language and environment for statistical computing. Vienna, Austria: R Core Team; 2019. http://www.R-project.org/. Kimball S, Mattis P. Gnu image manipulation program (gimp). GIMP. 2012;6:1–653. https://www.gimp.org/. He F, Mazumdar S, Tang G, Bhatia T, Anderson SJ, Dew MA, et al. Non-parametric MANOVA approaches for non-normal multivariate outcomes with missing values. Commun Stat Theory Methods. 2017;46(14):7188–200. PubMedPubMed CentralArticle Google Scholar Jackson CH, Sharples LD, Thompson SG, Duffy SW, Couto E. Multistate Markov models for disease progression with classification error. J R Stat Soc Ser D (The Statistician). 2003;52(2):193–209. Article Google Scholar Kuha J. AIC and BIC: comparisons of assumptions and performance. Sociol Methods Res. 2004;33(2):188–229. Article Google Scholar Vrieze SI. Model selection and psychological theory: a discussion of the differences between the Akaike information criterion (AIC) and the Bayesian information criterion (BIC). Psychol Methods. 2012;17(2):228. PubMedPubMed CentralArticle Google Scholar Magurran AE, Seghers BH. Population differences in predator recognition and attack cone avoidance in the guppy Poecilia reticulata. Anim Behav. 1990;40(3):443–52. Article Google Scholar Smallbone W, Ellison A, Poulton S, van Oosterhout C, Cable J. Depletion of MHC supertype during domestication can compromise immunocompetence. Mol Ecol. 2021;30(3):736–46. CASPubMedArticle Google Scholar Wileman D, Sangster G, Breen M, Ulmestrand M, Soldal A, Harris R. Roundfish and Nephrops survival after escape from commercial fishing gear. EC Contract No: FAIR-CT95-0753 Final Report. 1999 11;p. 1–241. Download references Not applicable. This study was funded by a Cardiff University Vice Chancellor’s international scholarship scheme for research excellence to C.T. School of Mathematics, Cardiff University, Abacws, CF24 4AG, Cardiff, UK Clement Twumasi & Owen Jones School of Biosciences, Cardiff University, Sir Martin Evans Building, CF10 3AX, Cardiff, UK Clement Twumasi & Joanne Cable Department of Statistics, Oxford University, 29 St Giles’, OX1 3LB, Oxford, UK Clement Twumasi You can also search for this author in PubMedGoogle Scholar You can also search for this author in PubMedGoogle Scholar You can also search for this author in PubMedGoogle Scholar C.T. and O.J. developed the mathematical methodologies. J.C. provided the empirical data. C.T. performed all statistical analyses and drafted the article. All authors conceived and designed the study, read and approved the final manuscript. Correspondence to Clement Twumasi. Not applicable. Not applicable. All authors declare that there are no conflicts of interest. Springer Nature remains neutral with regard to jurisdictional claims in published maps and institutional affiliations. Detailed visualisation of fish heatmaps over eight body regions of fish across parasite strains and fish stocks over time (from day 1 to 17). Grouped barcharts showing variations in mean intensities at four main body regions of fish across parasite strains and fish stocks over surviving fish and across time (from day 1 to 17). For simplicity, let (S_j sim exp left( lambda right)) with probability density (f(S_j)= lambda mathrm{e}^{-lambda S_j}, quad S_j>0) and (E(S_j)=frac{1}{lambda }), where (lambda =q_{12}(j,z_i)+q_{13}(j,z_i)). Suppose (alpha =t_j-t_{j-1}), then Considering the integral I and using integration by parts, where (u=S_j), (u^{prime }=1), (v^{prime }=mathrm{e}^{-lambda S_j}) and (v=-frac{1}{lambda }mathrm{e}^{-lambda S_j}). Hence, Substituting for (lambda) and (alpha) gives the required Eq. 9 such that Also, the required Eq. 10 can be obtained such that (square) Open Access This article is licensed under a Creative Commons Attribution 4.0 International License, which permits use, sharing, adaptation, distribution and reproduction in any medium or format, as long as you give appropriate credit to the original author(s) and the source, provide a link to the Creative Commons licence, and indicate if changes were made. The images or other third party material in this article are included in the article’s Creative Commons licence, unless indicated otherwise in a credit line to the material. If material is not included in the article’s Creative Commons licence and your intended use is not permitted by statutory regulation or exceeds the permitted use, you will need to obtain permission directly from the copyright holder. To view a copy of this licence, visit http://creativecommons.org/licenses/by/4.0/. The Creative Commons Public Domain Dedication waiver (http://creativecommons.org/publicdomain/zero/1.0/) applies to the data made available in this article, unless otherwise stated in a credit line to the data. Reprints and Permissions Twumasi, C., Jones, O. & Cable, J. Spatial and temporal parasite dynamics: microhabitat preferences and infection progression of two co-infecting gyrodactylids. Parasites Vectors15, 336 (2022). https://doi.org/10.1186/s13071-022-05471-9 Download citation Received: Accepted: Published: DOI: https://doi.org/10.1186/s13071-022-05471-9 Anyone you share the following link with will be able to read this content: Sorry, a shareable link is not currently available for this article.
The global battle for renewable energy resources is here, particularly battery metals and materials. The American startup, EnergyX, is leading the charge in revolutionizing the energy storage market with the development of sustainable lithium refining and battery technology. Behind this clean energy powerhouse is an unlikely figure, 34 year-old founder and CEO, Teague Egan. The serial entrepreneur, quickly becoming an energy mogul, has often been compared to Elon Musk. He was inspired to build the lithium company after a life-changing trip to South America in 2018. On the advice of a friend, Egan decided to backpack the picturesque Salar de Uyuni in Bolivia, the world’s largest salt flat at over 4,000 square miles. While touring the salt pan, Egan learned that this area making up part of the “Lithium Triangle” was also the world’s largest lithium reserve. As an early investor in Tesla, he had strong conviction that the world was shifting to electric vehicles, which meant massive quantities of lithium. What he didn’t know was that the technology to drastically increase the supply of this key battery metal was not yet commercially available. Who is Teague Egan? A South Florida native, Teague Egan found early success in the entertainment industry while attending University of Southern California. Earning his undergraduate degree in business entrepreneurship, he started a record label out of his dorm room, and his first album release quickly landed at #1 on iTunes. The son of early internet investor and entrepreneur Michael Egan, Teague attributes his entrepreneurial spirit to early childhood conversations with his father. “When I was 12 years old, dinner table conversations were about balance sheets, EBITDA, and complex problem solving,” Egan explains “as well as the trials and tribulations of entrepreneurship.” Fast forward to 28 years old, Michael told Teague to write down his 5 passions and the 5 industries he thought would be the biggest in the next 20-40 years. Now known as the 5&5 Exercise, the energy transition was something that overlapped on Egan’s list. With a lot of passion, precise timing, and a little luck, Egan found himself standing in the Saudi Arabia of lithium. A Moment of Inspiration Ultimately determining that the climate crisis was where Egan wanted to focus his time and energy, that trip to Bolivia was the juncture of vision and inspiration that drove Egan to leave entertainment and commit everything to solving the lithium supply chain issues. Within 4 years, EnergyX has catapulted into one of the leaders in Direct Lithium Extraction (DLE) and lithium refinery, boasting partnerships with some of the largest lithium producers in the world. The company won an international tender to deploy its pilot to Bolivia, and successfully operated the first ever DLE technology pilot plant in the Lithium Triangle with 94% recovery rate, only to be disqualified for turning in its final report 10 minutes late. There were rumors of external geopolitical factors involving Russia and China, the other competing entities, were at play. Now with over $450M in funding commitments, and already featuring an all-star team of PhD’s, chemical engineers, and clean energy veterans, EnergyX most recently announced an interesting addition to their advisory board, A-List super-firm Endeavor, whose fearless leader is none other than Ari Emanuel. Full Circle with Ari Emanuel During Egan’s first career in Hollywood, his record label represented breakout musician Sammy Adams who performed at shows across the nation to sell out crowds. Coincidentally, Egan’s artists were represented by Endeavor’s William Morris Agency (WME) whose talent roster also includes the likes of musicians Usher, Bruno Mars, and Foo Fighters, actors Denzel Washington and Jessica Alba, sports stars such as Tom Brady, and a host of other talents. The Endeavor Group has also committed to ‘Endeavor Impact’, a company-wide commitment to equity, democracy, inclusion, and sustainability that is a core element of this advisory. “It was literally 10 years after the record label, and I got a call that said WME on my caller ID,” says Egan. “When I picked up, it was Ari Emanuel himself asking about EnergyX and our featured cover story on the front page of New York Times.” With a mission focused on sustainability, Endeavor’s team will help drive awareness and strategic conversation around the future of energy. It’s no doubt that the firm’s cultural footprints in the world of entertainment, sports, and media could be key to bridging EnergyX’s vision and technology to help combat the climate crisis and quicken the world’s transition to renewable energy. A New Approach While lithium is the critical component in electric vehicle batteries, the extraction of this metal has caused some serious environmental and social concerns over the years. Egan hopes to break this narrative by placing sustainability at the heart of technological innovations in lithium extraction. Elon Musk recently commented in Tesla’s Q2 earnings that “lithium refining is like having a license to print money.” Over the last year, the metal’s price has skyrocketed, going from $10,000 to $80,000 per ton influenced by demand from large car companies such as GM, Ford and Tesla, in addition to new government regulations pushing for Net-Zero and Low Carbon initiatives. From entertainment breakout to energy titan, Egan and team are now revolutionizing the renewable energy industry. Through an unlikely partnership between Egan and Emanuel, they hope that Endeavor Impact’s mission, A-list celebrities, and the savvy marketing and influence of Endeavor can help to spread the important message of fighting climate change. Whether this duo can crack the code to sustainable lithium extraction is at the center of crucial questions on climate, energy, and the future of technology. Learn more about Teague Egan, and the future of lithium at EnergyX. I am a Singer, Songwriter, College Graduate with BBA & Co-Founder/Editor-In-Chief of stupidDOPE.com. I was born and raised in South Carolina, currently live in Florida. Subscribe now to our newsletter Input your search keywords and press Enter.
Craig Kimbrel told he won’t be Dodgers’ closer before Albert Pujols’ historic game By Steve Henson Craig Kimbrel is no longer the Dodgers’ closer. There. Dave Roberts said so Friday. Finally. The words came haltingly, with thoughtful pauses, but they came. “I just think that right now, um, I’m going to keep Craig down tonight,” Roberts said. “And my expectation is, yeah, I talked to him today. Right now the plan is to change roles and get him into a position to pitch in different innings in different situations. “He was very open to doing whatever is best for the ballclub. So I feel good about it and we’ll see where that takes us.” Dodgers Mookie Betts’ pinch-hit single lifted the Dodgers to a 3-2 walk-off win over the Arizona Diamondbacks on Thursday at Dodger Stadium.
Roberts comments came ahead of the Dodgers’ 11-0 loss to the St. Louis Cardinals at Dodger Stadium highlighted by Albert Pujols joining Barry Bonds, Hank Aaron and Babe Ruth in the 700 home run club. The former Dodgers and Angels slugger hit a two-run homer off Andrew Heaney in the third inning and a three-run shot off Phil Bickford in the fourth to the delight of a crowd of 50,041. When the sixth inning rolled around, Roberts contradicted his pregame statement by calling on Kimbrel with the Dodgers trailing 8-0. Is the new role of a reliever with 394 career saves mop-up man? It’s hard to know how best to use him. Kimbrel did retire Pujols on a groundout to shortstop. Kimbrel gave up a home run in the ninth inning Thursday that put the Arizona Diamondbacks ahead by a run. The Dodgers won in the bottom of the inning on Mookie Betts’ walk-off single, which gave Kimbrel the win. That clearly was the last straw for Roberts. Kimbrel, 34, has blown five of 27 save opportunities and has a 4.07 ERA in 58 appearances this season. Only 12.1% of his pitches swung at are missed, about league average. Yet he is seventh all-time in career saves and led the league in saves four consecutive years ending in 2014. Perhaps that’s why Roberts and the Dodgers front office stuck with him so long even though his effectiveness had obviously diminished from his heyday. Roberts said he appreciated the way Kimbrel took the news that he was no longer the closer. “My job is to find the best lane for him and he has no worries of changing the routine from something he’s always done,” Roberts said. “He looks at it as a challenge. That’s the way we would expect it and it speaks a lot to him as a team player.” Roberts said no one reliever will assume the closer role for now. Evan Phillips (6-3, 1.24 ERA), Brusdar Graterol (2-3, 2.96) and Alex Vesia (4-0, 2.26) are the obvious candidates. Obituaries Maury Wills, who revolutionized baseball with his ability to steal bases and was the MVP of the National League in 1962 for the Dodgers, has died.
“No, for us it’s finding, it’s treating him like we treat all of our guys, putting them in the best position to get outs,” Roberts said. “That’s kind of how I’m going to approach every inning for the ‘pen.” Phillips, 28, has been the undisputed top reliever all season, giving up 29 hits in 58 innings while striking out 68. He’s in line for closer duty, although his value has been putting out fires regardless of the inning. Also, he has only three career saves, two this season. Phillips said he wouldn’t treat the ninth inning differently than any other. “I think the best thing you can do as the guy coming out to finish the game is to provide consistency throughout the season,” he said. If a closer-by-committee approach fails, the Dodgers face a situation where a new closer must emerge with the postseason around the corner. Phillips didn’t sound like he would be fazed. “I don’t really value that role any higher than what I do now,” he said. “I think the [Dodgers] really instilled in us that when the phone rings you go out there and get your outs. So regardless of the situation, and it might be the ninth inning or a tight ballgame, however you want to phrase it, my challenge is that when the phone rings, I do my job.” Kimbrel likely will be used almost exclusively against right-handed hitters, who are batting .208 with a .603 on-base-plus-slugging percentage against him. Left-handers are hitting .266 with a .786 OPS. Silencing the Dodgers on Friday was longtime nemesis Jose Quintana, who pitched six scoreless innings, reducing his ERA in 12 career games against the Dodgers to 1.80. The left-hander struggled to a 6.75 ERA in 24 appearances with the Angels in 2021 but has posted a 3.04 ERA in 30 starts with the Cardinals and Pittsburgh Pirates this season. Roberts said injured starter Tony Gonsolin had normal soreness “which is a good thing” a day after he pitched two innings in a simulated game at Dodger Stadium. Roberts said Gonsolin is scheduled to pitch two innings in a rehab game at triple-A Oklahoma City. “ Another home run for the Cardinals It’s the eighth inning and Hanser Alberto is pitching for the Dodgers. It’s officially become a don’t-waste-the-bullpen game for the Dodgers. Alec Burleson took advantage of that fact by hitting his first career home run — a solo shot to right field — to give the Cardinals an 11-0 lead. It was the fifth home run of the game for the Cardinals. Alec Burleson collects his first MLB homer! pic.twitter.com/TKn5T3rmsv The Dodgers are on pace for their worst shutout loss since 2018. ⚾ End of eighth: Cardinals 11, Dodgers 0 Cardinals homer again, take 10-0 lead in the seventh Albert Pujols isn’t the only player on the Cardinals hitting home runs tonight. Juan Yepez hit his 12th home run of the season off Dodgers reliver Caleb Ferguson, slinging a 95-mph fastball just inside the left-field foul pole to help the Cardinals take a 10-0 lead in the seventh inning. It was the fourth home run hit by the Cardinals. After Yepez’s solo shot made it 9-0, Lars Nootbar drove in another run two batters later on a grounder to center field. The Dodgers certainly don’t look like a 100-win team tonight. With all the woes the bullpen has been experiencing — including the situation involving Craig Kimbrel — is it cause for concern or an anomaly on dominance street? ⚾ Middle of the seventh: Cardinals 10, Dodgers 0 Cardinals continue to hammer Dodgers pitching After Albert Pujols punched the Cardinals to a 5-0 lead with his 699th and 700th career home runs, St. Louis continued to pour it on against the Dodgers. The Cardinals scored three more runs off Phil Bickford in the sixth inning. Dylan Carlson doubled in a run before Lars Nootbaar hit a two-run homer to right field to give the Cardinals an 8-0 lead. Albert Pujols hits home run No. 700 Cardinals slugger Albert Pujols hit his 700th career home run in the fourth inning off Dodgers reliever Phil Bickford, giving St. Louis a 5-0 lead. The three-run shot was another no-doubter, landing in the left-field pavilion. Dodger Stadium erupted in cheers with players on the Cardinals congratulating Pujols and Dodgers players clapping in appreciation. 7️⃣0️⃣0️⃣ #Pujols700pic.twitter.com/XyddSFPpcQ Pujols then came out of the dugout and acknowledged the crowd. Read more >>> Albert Pujols hits home run No. 699 Albert Pujols hit his 699th career home run in his second at-bat against the Dodgers in the third inning Friday night, clobbering a pitch from Andrew Heaney into the pavilion in left-center field at Dodger Stadium. No doubt about number 699 for #AlbertPujols! pic.twitter.com/2Ns3ueuzcn It was a no-doubter, Pujols extracting everything on the pitch for a two-run blast deep into the pavilion seats, giving the Cardinals a 2-0 lead. Pujols is one home run away from joining Barry Bonds (762), Hank Aaron (755) and Babe Ruth (714) as the only players in major league history to hit 700 home runs. Albert Pujols hits No. 699 and Dodger Stadium cheers. pic.twitter.com/I7chdj5mWd ⚾ Middle of third: Cardinals 2, Dodgers 0 Albert Pujols strikes out in first at-bat vs. Dodgers By Austin Knoblauch Dodgers starter Andrew Heaney struck out St. Louis Cardinals slugger Albert Pujols with a 95-mph fastball during his at-bat in the first inning. Pujols, sitting on 698 career home runs, received a standing ovation from many of the fans in attendance at Dodger Stadium, where Pujols spent most of his 2021 season. Pujols is looking to become only the fourth player in major league history to hit 700 home runs. He said will retire at the end of the season. ⚾ Middle of the first: Cardinals 0, Dodgers 0 Craig Kimbrel ousted as Dodgers closer By Steve Henson Craig Kimbrel is no longer the Dodgers closer. There. Dave Roberts said so Friday. Finally. The words came haltingly, with thoughtful pauses, but they came. “I just think that right now, um, I’m going to keep Craig down tonight,” Roberts said. “And my expectation is, yeah, I talked to him today. Right now the plan is to change roles and get him into a position to pitch in different innings in different situations. “He was very open to doing whatever is best for the ballclub. So I feel good about it and we’ll see where that takes us.” Kimbrel gave up a home run in the ninth inning Thursday that put the Arizona Diamondbacks ahead by a run. The Dodgers won in the bottom of the inning on Mookie Betts’ walk-off single, which gave Kimbrel the win. Dodgers Mookie Betts’ pinch-hit single lifted the Dodgers to a 3-2 walk-off win over the Arizona Diamondbacks on Thursday at Dodger Stadium.
But Kimbrel, 34, has blown five of 27 save opportunities and has a 4.14 ERA in 57 appearances this season. He is seventh all-time with 394 saves in 13 seasons and led the league in saves four consecutive years ending in 2014. Perhaps that’s why Roberts and the Dodgers front office stuck with him so long even though his effectiveness had obviously diminished from his heyday. Roberts said he appreciated the way Kimbrel took the news that he was no longer the closer. “He’s such a professional and knows that there is more there, more consistency, just the openness to do what’s best,” he said. “My job is to find the best lane for him and he has no worries of changing the routine from something he’s always done. He looks at it as a challenge. That’s the way we would expect it and it speaks a lot to him as a team player.” Roberts said no one reliever will assume the closer role for now. Evan Phillips, Brusdar Graterol and Alex Vesia are the most obvious candidates. “No, for us it’s finding, it’s treating him like we treat all of our guys, putting them in the best position to get outs,” Roberts said. “That’s kind of how I’m going to approach every inning for the ‘pen.”
Rejuvenated Albert Pujols brings his chase for 700 home runs to Dodger Stadium By Mike DiGiovanna SAN DIEGO — When the bat of Albert Pujols caught fire in early August, and it appeared the St. Louis Cardinals slugger would make an improbable 11th-hour run to 700 homers, Mark McGwire began tracking his long-ago teammate through the MLB app and tuning into as many Pujols plate appearances as he could. “His at-bats, he looks like he’s 25 again,” McGwire said of the 42-year-old Pujols, who was a Cardinals rookie when McGwire hit the last of his 583 career homers in a St. Louis uniform in 2001. “This guy is a born hitter.” But it wasn’t until McGwire returned to Busch Stadium for Matt Holliday’s Cardinals Hall-of-Fame induction ceremony on Aug. 27 that he truly grasped — literally, not figuratively — how Pujols, in his 22nd and final big league season, has recaptured the thunder in his swing. Read more >>> ICYMI: Mookie Betts lifts Dodgers with walk-off win over Diamondbacks By Steve Henson Four hours before the Dodgers defeated the Arizona Diamondbacks 3-2 Thursday on a walk-off hit by Mookie Betts, the eyes of everyone in blue were riveted on the Dodger Stadium pitcher’s mound. Manager Dave Roberts and bench coach Bob Geren stood near the third-base line, arms folded. President of Baseball Operations Andrew Friedman watched while engaged in conversation with Betts. A good half-dozen Dodgers pitchers leaned against the dugout railing, observing every pitch. Nobody needed to state the obvious: What they were witnessing could seriously impact their postseason fortunes. Tony Gonsolin, on the injured list since Aug. 29 with a forearm strain, was pitching to teammates Gavin Lux, Chris Taylor, Hanser Alberto and Miguel Vargas. The All-Star right-hander held nothing back, throwing his four-seam fastball, slider, curveball and split-finger fastball. Read more >>> How to watch and stream the Dodgers this season Here’s a look at the Dodgers broadcast and streaming schedule for the remainder of the 2022 regular season:
Live Feed The Dodgers (104-47) lost to the St. Louis Cardinals (89-63) at Dodger Stadium on Friday. Here’s a recap of the game.
byRandy Melodic bass producer Egzod releases his brand-new single, “The Way Out,” featuring Bertie Scott, via Spinnin’ Records. “The Way Out” delivers a cinematic journey, exploring the emotions of “something slipping away.” Born in Portugal, raised in France, and now based in the U.S., Egzod has amassed more than 200 million streams and millions of international fans, including over two million monthly listeners on Spotify. Egzod, which means “Exodus” in French phonetics, is the narrative of a mass departure of people to another world where technology and nature are in perfect balance. Through his music, blending sounds and instruments from around the globe, Egzod works to empower and unify people. Appearing soon at Firefly Music Fest and EDC Orlando, Egzod’s new tracks will provide a “way out” towards exciting musical fantasies. CelebMix spoke with Egzod to discover more about the person behind the music, how he got started in music and his definition of tone.
What inspired your new single, “The Way Out?” I have been finding a lot of inspiration in Hardwave in the past years as it is very cinematic but also combines both of my favorite influences: the melodic content from Trance and the heaviness of Bass music. Bertie Scott sent over some toplines and “The Way Out” fitted perfectly on a track I was working on, both lyrically and melodically. Where and when did you connect with Bertie Scott? I connected with Bertie Scott via Instagram last year. We’ve been going back and forth on different music ideas ever since. We recently finished another track together actually. How did you get started in music? I first got into making music through the art of DJing at the age of 13. I’d spend time making mashups and mixes up until the end of high school. Starting college, I switched to music production because I wanted to start making my own records. Where are you from? I was born in Portugal, close to Porto, and I grew up in the South of France. I’m currently based in Florida. Did your hometown impact your music? It did quite a lot. Electronic music has always been big in France – from the French Touch scene in the ‘90s/early 2000s with artists like Daft Punk, Justice, David Guetta, Martin Solveig, Breakbot – and now more recently in bass and house music in the past decade with artists like DJ Snake, Dirtyphonics, Habstrakt, Malaa, Tchami, CloZee. However, I’d say what influenced me more than my hometown, is the internet. I think that a lot of subgenres like Future Bass, Trap, Hardwave, and Dubstep exploded thanks to online forums and curators/labels on Youtube and other platforms in the past decade. Did your sound evolve naturally, or did you deliberately push it in a certain direction? I’d say that I pushed it to a certain direction, being bass music blended with some orchestral elements. Then from there, my sound evolved naturally. I think it’s a never-ending process which makes music production always exciting. How do you define tone? And has your tone changed over time? Lately, it has shifted from an orchestral/eastern tone to a more futuristic/hybrid style I would say. Although, I tend to always keep it melodic. As mentioned previously, I think it’s a never-ending process and an artist’s style or tone evolves forever, although the essence is kept. What inspires your writing? Do you draw inspiration from poems, music, or other media? Definitely a lot of fantasy and sci-fi movies (ex: LOTR, Ghost In The Shell, Matrix) – but also digital art and 3D animation (ex: Beeple). I listen to all music genres on a daily basis which helps me find inspiration as well. What can you share about your writing process? I love resampling my own work that has never been released. Some of my biggest releases have come out of old projects that I would recycle or resample. Tip for the producers out there: keep ALL your works in progress stored – you’d be surprised what could happen with them years down the road. Which artists in your opinion are killing it right now? I’m maybe biased because I’ve collabed with most of them but I’m genuinely a fan of their work. Here is the list in no particular order: if found, Afinity, Slippy, Arcando, Memba, Maazel, Nurko, Abandoned, Madzi, and Sublab. How do you define success? Success is the accomplishment of a purpose. Part of society has put a lot of focus on success being exclusively related to numbers and the achievement of goals. I’d say it’s not exclusive to that and goes beyond those. Goals are a point of view to achieve – a purpose is the reason why we want to achieve these goals. I think finding the reason is what brings success. What can your fans look forward to over the next six months? Music videos? Live gigs? I’m very stoked to be playing at Firefly for the first time and EDC Orlando this year. I’m excited to be making my debut on Spinnin’ Records as well with “The Way Out” which will be released with its lyric video. Expect lots of new originals and remixes following this release! Follow Egzod Instagram | Twitter | Facebook | Spotify Randy Radic is a Left Coast author and writer. Author of numerous true crime books written under the pen-name of John Lee Brook. Former music contributor at Huff Post. Read More View Gallery Read More Read More View Gallery Read More Read More Read More Read More Read More 2022 CelebMix Sağlık Personeli
Sign up for email newsletters E-Edition A 29-year-old Warren woman was convicted Thursday of second-degree murder and second-degree child abuse for fatally starving her 7-week-old son. A Macomb County Circuit Court jury deliberated about two hours following a more than one-week trial before announcing the conviction of Shantavia Hayden for the October 2020 death of A’mir Griffin. “We are happy that the jury listened intently to all of the evidence and rendered a verdict that delivered justice for baby A’mir,” Assistant Macomb Prosecutor Colleen Worden said following the verdict. Hayden faces a term of any number of years up to life when she is sentenced Nov. 2 by Judge James Biernat Jr. Her sentencing guideline range suggests a minimum term of 13-½ years behind bars, Worden said. During closing arguments Thursday morning, Assistant Prosecutor Molly Zappitell told jurors A’mir went from a normal baby after birth to a malnourished child his entire brief life. “Everything was fine with A’mir except he didn’t have food,” Zappitell said. “He starved to death. There is no other cause of death.” Prosecutors didn’t have to explain why Hayden failed to care for her child. “It’s something we all struggle with, but it’s not something I have to prove,” Zappitell said. At the start of the trial, a few supporters of Hayden attended the trial, but none were present for closing arguments. Hayden brought an unresponsive A’mir to Children’s Hospital of Michigan in Detroit at 5:30 a.m. Oct. 11, 2020. Children’s Hospital emergency room physician Dr. Jennifer Noble testified last week A’mir had been dead for a few hours as he was showing signs of rigor mortis. She said she still performed life-saving efforts. “The skin is draping around the bones because there is no fat left. The fat has been used,” Noble said of A’mir’s condition. Zappitell displayed two photographs of A’mir on a big screen: one from the hospital and one from his autopsy which shows his extremely malnourished condition. A’mir at the hospital was “a chunky little baby. Look what happened to him seven weeks later,” she said. Dr. Leigh Hlavaty, who performed the autopsy, testified last week that A’mire’s stomach and colon were empty, meaning the child had received no nourishment for at least seven days. Hlavaty, who was the deputy medical examiner in Wayne County at the time, said A’mir’s body began to consume his muscles to try to stay alive. A’mir’s weight declined from his birth weight of over 5 pounds, she said. Zappitell asserted Hayden may not have intentionally tried to kill Amir but created a high risk of death or great bodily harm in which death was a likely result, an element of second-degree murder. She speculated perhaps Hayden was angry at A’mir’s father for not being involved with the child, although one of her three other children was also fathered by him, Zappitell said. She said the three other children were “very well fed.” Hayden never took A’mir for a doctor’s visit and downplayed his condition to paramedics after she called 911 to her residence 10 days before Amir’s death due to him choking up baby formula, Zappitell said. Zappitell accused of Hayden of lying to police when she said after the baby’s death she had fed him 12 hours before and had been feeding him three to four bottles of baby formula per day, although that amount is about half of what a baby needs to survive. During her police interview, Hayden repeatedly said she fed her baby. After the questioning was over and she was alone in the interview room, she said, “I don’t know what the f— to do. I hurt my baby,” according to a video-audio recording. Hayden lied to receive more governmental assistance than she was entitled to, such as state unemployment benefits, and federal benefits under Women, Children, Infants (WIC), Zappitell said. “That goes to her character to assess credibility,” Zappitell said. She obtained 16 cans of food from WIC during A’mir’s life, seven of them three days before he died. She received $15,000 in jobless benefits in four months as well as food stamps and cash from the state, the prosecution showed. Zapitell said Hayden may have spent some money on drugs as there is evidence she was a drug user. A’mir was born with drugs in his system but by the time he left the hospital four days later, was drug-free and a normal baby, according to testimony. During his closing argument, Hayden’s attorney, Andrew Hubbs, said Hayden did not receive more benefits than she deserved and that she “was a struggling mother.” After A’mir’s death, she was “struggling with the loss of her child,” he said. He asked jurors to find her not guilty because the “prosecution has not proved its case” and “so she can move on with her life and the grieving process.” Judge James Biernat Jr., who presided over the more than one-week trial, rejected Hubb’s request to allow the jury to consider manslaughter as a potential verdict. Woman accused of starving baby to death in Warren rejects plea
Watch #Kimmel Clips: Interviews | Music Performances | Unnecessary Censorship | Lie Witness News | Mean Tweets Jimmy Kimmel Live airs every weeknight at 11:35 p.m. EDT and features a diverse lineup of guests that include celebrities, athletes, musical acts, comedians and human-interest subjects, along with comedy bits and a house band. The following episodes are scheduled to air the week of Sept. 26-30 (subject to change): Monday, Sept. 26 Amy Schumer ("Whore Tour"), Charlamagne Tha God ("Hell of a Week"), Musical Guest Run The Jewels Tuesday, Sept. 27 David Letterman, Tracy Morgan ("No Disrespect") Wednesday, Sept. 28 Mila Kunis ("Luckiest Girl Alive"), Ramy Youssef ("Ramy"), Musical Guest Future Thursday, Sep. 29 Ben Stiller ("Severance"), Musical Guest Yeah Yeah Yeahs Friday, Sept. 30 Jason Bateman, Paul Simon, Musical Guest Paul Simon Enjoy Jimmy Kimmel Live! on the web at abc.com and at youtube/JimmyKimmelLive.
Indonesia’s President discusses Russia, China, EVs and resource nationalism with Bloomberg’s Editor-in-Chief John Micklethwait. Bloomberg View columnist Barry Ritholtz looks at the people and ideas that shape markets, investing and business. As prominent equestrians are banned and even arrested, some traditionalists are taking aim at the Olympic watchdog created to protect young athletes. Most Thais Don’t See Suitable Candidate for Premier, Poll Shows China Traders See Property Boost, Covid Zero Resolve at Congress Mazda Sees No Return Path to Production in Russia, Yomiuri Says Sinema Says Arizona Abortion Ruling Removes Basic Women’s Rights PGIM’s Head Quant Advises Patience With Fed’s Inflation Battle NASA Delays Artemis I Moon Launch Again on Tropical Storm Risk Australian Police Probe Optus Cyberattack as Data Threats Emerge Bolsonaro Becomes Main Target in Brazil Debate Without Lula UK’s Truss Plans More Tax Cuts Next Year, Telegraph Reports Americans Are Tapping Home Equity Despite Jump in Rates Hedge Fund D.E. Shaw Is Shifting HQ to Manhattan West Tower Judge Still At 60, Homerless in 4th Straight, Yanks Win 7-5 Pharoah Sanders, Influential Jazz Saxophonist, Dies At 81 America’s New Secession Movements Aren’t a Crime Putin’s Ukraine War Forces Ugly Bargains on Food and Fuel 2022’s Housing Market Will Be a Defining Moment To Find Success at Work, Match Your Job With Your Personality US Is Inflating Its Debt Away After Unprecedented Spending Binge Columbia Business School Reimagines Its Future With a New Campus Dissident: ‘Iranian Women Are Furious’ Over Headscarf Death Who Wins Most From Kwarteng’s Tax Bonanza? Florida Emergency Declared as Tropical Storm Ian Strengthens NASA Delays Moon Rocket Launch Due to Potential Hurricane The Building Game That Doesn’t Let You Build LA Looks to Beat New York Back to Pre-Pandemic Transit Ridership The Next Step on Climate Action: Parking Reform Crypto DAOs and Their Token Holders Aren’t Safe From the CFTC Cryptocurrencies Extend Drop as ‘Tough Environment’ Culls Demand Assessing China’s Crypto Ban One Year Later President Vladimir Putin’s order to call up as many as 300,000 reservists to fight in Ukraine triggered alarm and demonstrations as Russians were forced to confront the reality of the deadly conflict. Police detained about 1,400 people at protests against the order in 38 cities Wednesday night, according to the OVD-Info monitoring group. Some of the male detainees were handed draft notices at police stations, and protesters may face criminal charges under the harsh laws against criticism of the war the Kremlin has imposed since the Feb. 24 invasion. Some university students who joined the demonstrations were threatened with expulsion, which could annul draft exemptions.
Grimes has a new album on the way; This past weekend, she revealed that it’s done and just in the mixing stages now. Speaking of music production, Grimes just hit a significant setback, revealing today (September 23) that she just lost “80 hours worth of work that cannot be recovered.” The silver lining, though, is that the lost work wasn’t her new album. This morning, Grimes shared a photo of a home studio setup and tweeted, “My work realm is rly peak rn but my computer just ate about 80 hours worth of work that cannot be recovered RIP. I am depressed about this ngl.” My work realm is rly peak rn but my computer just ate about 80 hours worth of work that cannot be recovered RIP. I am depressed about this ngl pic.twitter.com/vWpjr27HVs — 𝔊𝔯𝔦𝔪𝔢𝔰 (@Grimezsz) September 23, 2022
It’s not clear if “80 hours worth of work” means 80 hours of music or 80 hours of time spent working on the now-lost music. Somebody suggested seeking help from a computer expert and Grimes replied, “Nah I’ve tried every angle – ableton had a saving issue it Couldn’t y save and I was trying to take bits of the file to new sessions and every session that got a piece of the original session also for cursed and couldnt save and then it all disappeared.” Somebody else commented, “we never gonna get these albums i’m done,” and Grimes responded, “No it was extra, album is done, it’s just if I make 2 more songs it’s a double album so that’s preferable but maybe it’s not destiny cuz I’m too tired.” Nah I’ve tried every angle – ableton had a saving issue it Couldn’t y save and I was trying to take bits of the file to new sessions and every session that got a piece of the original session also for cursed and couldnt save and then it all disappeared — 𝔊𝔯𝔦𝔪𝔢𝔰 (@Grimezsz) September 23, 2022
No it was extra, album is done, it’s just if I make 2 more songs it’s a double album so that’s preferable but maybe it’s not destiny cuz I’m too tired — 𝔊𝔯𝔦𝔪𝔢𝔰 (@Grimezsz) September 23, 2022
At the very least, Grimes still has her post-plastic-surgery recovery to look forward to.
Digital News Writer, PEOPLE A New York City reporter received the surprise of a lifetime at work. Michelle Ross, a reporter for local CW affiliate WPIX, was on-air Wednesday when her boyfriend quietly got down on one knee behind her, as captured in a sweet video shared by the station. Of course, Ross had no idea — and the person she was interviewing gave no hint as to what was about to happen either. But when Ross went to send the broadcast back to the studio, one of her anchors asked, "Who's that behind you?" She then turned around to find her boyfriend, Robert Tilearcio Jr., kneeling in front of a banner that read: "Will you marry me?" "I've waited 10 years for this," he said in the video. "You're the love of my life, and I definitely want to ask, 'Will you marry me?'" "I love you, of course," she tearfully answered. Never miss a story — sign up for PEOPLE’s free daily newsletter to stay up-to-date on the best of what PEOPLE has to offer, from juicy celebrity news to compelling human interest stories. The news station also shared the touching video on their Instagram page. "Congrats to PIX11's @michellearezouross ! 💍 She was doing a live interview when her FDNY boyfriend and family members surprised her in Battery Park," they captioned the clip. "Spoiler alert: She said yes. ❤️" And the comments section was filled with warm messages from her colleagues. "So happy for you and your fiancé, Michelle! What a proposal!" wrote one, while another added, "Congrats, Michelle! I am so happy for you! I keep crying every time I watch this!" After saying yes, Ross showed off her ring and introduced her new fiancé. "This Bobby my boyfriend, now fiancé. He's a firefighter in Brooklyn," she said. "I can't believe all my family and friends are here. I'm totally caught off guard." Her mother then shouted in excitement, "We pulled it off!" "You did a good job," she said to her husband-to-be. "Thank you, guys." By clicking “Accept All Cookies”, you agree to the storing of cookies on your device to enhance site navigation, analyze site usage, and assist in our marketing efforts.
Partly cloudy skies this evening will give way to occasional showers overnight. Low 57F. Winds WSW at 5 to 10 mph. Chance of rain 40%.. Partly cloudy skies this evening will give way to occasional showers overnight. Low 57F. Winds WSW at 5 to 10 mph. Chance of rain 40%. Updated: September 24, 2022 @ 10:54 pm Nancy Roe vs. Purdue University is being held this week in Northern Indiana District Court.
Nancy Roe vs. Purdue University is being held this week in Northern Indiana District Court. HAMMOND, Indiana – A male student finished serving drinks at Acacia Fraternity house about 1 a.m. The student, referred to in court documents as Student B, was talking to a female student, referred to as Nancy Roe. Roe had become extremely intoxicated that April 2017 night, drinking the equivalent of 18 drinks’ worth of wine and beer, according to Purdue’s Title IX investigators. Student B served some of those drinks to Roe, then 19. Student B walked Roe back to her room in Harrison Residence Hall about an hour later and had sex with her. While in bed, Student B created an audio recording of their conversation. He told investigators he did so because he knew she would later claim rape. He later played that recording for his fraternity brothers, presumably to prove his innocence. Roe filed a sexual assault report to Purdue at the end of the week, claiming she was too drunk to consent to sex. Purdue’s Title IX office investigated and found Student B innocent of sexual assault but guilty of sexual exploitation for recording without her consent. As punishment, he was assigned a 10-page paper on sexual exploitation and the importance of consent before sex. For making what Purdue claims is a false statement, Roe was expelled. “I read that decision,” Roe said in her Tuesday testimony, a small pile of tissues accumulating on the table in front of her, “and it felt like my whole world was closing in on me.” The possible gender disparity displayed in the punishments is a focal point of a five-day jury trial against Purdue. Roe, whose 2017 expulsion was later amended to a two-year suspension, brought allegations of gender discrimination and violation of Fourteenth Amendment due process in a 2018 lawsuit against Purdue as well as Vice President for Ethics and Compliance Alysa Rollock and Associate Vice Provost and Dean of Students Katie Sermersheim, both of whom were active in Roe’s investigation. Another woman, referred to as Jane Doe, was originally part of the lawsuit because she was also expelled under unrelated but similar circumstances. Doe settled with Purdue outside of court on Aug. 31, according to the court docket. ‘The worst 12 hours of her life’ Roe said she awoke the morning after the incident in her own room, with no memory of the previous night. She learned through a series of what she called “unusual” text messages that she had a sexual encounter with Student B. The texts contained sexually and otherwise explicit language, including Roe saying she wished they could have sex again. She later recalled Student B putting his phone number in her phone Monday night, saving his contact as his first name and “Acacia.” “(He) said I would be too drunk to remember his last name,” Roe said. Expert witness will testify in Roe vs. Purdue today Scared, confused and ashamed, Roe said she agreed to Student B coming over that afternoon, intending to talk about what happened. He confirmed that they had sex the night before, and then they had sex again. “It would be easier to kill myself if I could tell myself I cheated on (my boyfriend, because then it would be my fault),” she said when asked why they had sex a second time. Roe’s attorney, Jeffrey Macey, described the experience as “the worst 12 hours of (Roe’s) life.” “I feel like I blocked everything,” Roe said. “All I remember (from Tuesday afternoon) is how much it hurt. I wanted it to end. I wanted him to leave.” Was Roe too ‘incapacitated’ to consent? The case hinges on whether the jury believes Roe lied about being “incapacitated,” thus too drunk to consent to sex. The Association of Title IX Administrators holds that “An incapacitated person could be stark naked, demanding sex, but if they are incapacitated at the time, and that is known or should be known to the responding party, any sexual activity that takes place is misconduct, and any factual consent that may have been expressed is IRRELEVANT. “For example, a blacked-out person may say “yes” when asked if they want to have sex but, if incapacitated, they will not know they are saying it.” William Kealey, one of Purdue’s attorneys, played during his opening statement the nine-minute audio recording that Student B made. In it, Roe’s voice sounds slowed and slightly delayed, and she giggles often. She more than once asks him to perform different sexual acts on her, and she asks him to stay multiple times. Kealey and Sermersheim argued that the audio proved Roe was able to hold a conversation, and therefore was able to consent. But Macey asked the jury to consider how drunk she sounds in the recording. “I can’t describe how it feels,” Roe said on the stand between deep breaths and sniffles when asked about listening to it. Roe’s then-boyfriend described her that night as “very drunk.” In his report to the investigators, he told them that she was “loopy and floppy and could not sit up straight. She was black-out drunk and slurring her speech.” “There was no way I could have consented,” Roe said. “I was too intoxicated. It wasn’t OK that it happened, and he should have known that it wasn’t OK that it happened.” Student B told investigators that he recorded their conversation without her consent because he knew she would claim it was rape. In the recording, which was played in court Monday, Roe’s speech is slow and slurred, while Student B’s voice remains steady, absent of evidence that he was also drunk. Still, Sermersheim maintained that Roe wasn’t “incapacitated.” “Just because you don’t remember something doesn’t mean it’s rape,” she said. Sermersheim defined incapacitated as being unresponsive and unable to speak, hear or move. But Macey produced a copy of Purdue’ sexual harassment resource guide. It says “consent cannot be given based off silence, passivity or when an individual is incapacitated or otherwise prevented from giving consent.” The guidelines define incapacitated as “a mental state in which an individual cannot make rational decisions because they lack the capacity to give consent.” “It doesn’t say a person cannot move,” Macey said. “It doesn’t say ‘cannot make decisions.’ It says ‘cannot make rational decisions.’” Macey said while questioning Sermersheim that Roe being incapacitated was the only disputed claim, concluding that the claim is the reason she was expelled. But Sermersheim said being incapacitated was just one false statement she made. Macey asked what other false statements Roe made, and Sermersheim rattled off what she considered evidence for why she wasn’t incapacitated: She could walk back to her room, she could talk, she could use an elevator and more. “But she didn’t deny all those things,” Macey said. He again asked what other false statements Roe made, sounding frustrated, and Sermersheim gave the same answer. Macey asked a third time, but Kealey objected, saying the question had already been answered. Magistrate John Martin eventually sustained the objection after Macey tried to ask the question again, and Macey was forced to move on. Gender discrimination? Roe’s attorneys argue that Student B’s punishment for sexual exploitation, which is a felony, was unfair when compared to the discipline Roe received for allegedly making a false statement in her sexual assault report. Kealey spent much of Tuesday’s cross examination challenging this assertion. “(Sermersheim) suspended you because she believed you made false statements,” he said to Roe. “Not because you’re a woman.” ‘I want to be listened to’: Plaintiff testifies in first day of gender discrimination case against Purdue Roe was punished because she allegedly lied about the incident, but Student B lied as well, Macey said. He originally told friends Roe was throwing up to justify why he needed to spend more time with her that night. Student B later told investigators that he lied about Roe throwing up. Despite that inconsistency in his story, Sermersheim said she found Student B to be a “credible source” but found Roe to be uncredible. Due process questions Roe’s lawyers alleged Tuesday that neither Sermersheim nor Rollock gave Roe due process when they expelled her from Purdue. Roe first learned that Purdue found Student B to be innocent of sexual assault in a letter from Rollock received in mid-August of 2017. Rollock later also told Roe she would be referred to the Office of Student Rights and Responsibilities for an investigation into her decidedly false claim that she was “incapacitated.” But Roe still had a chance to appeal. She prepared a document for her appeal estimating her BAC level that night. Based on Purdue investigators’ findings that she consumed roughly 18 drinks of wine and beer, she estimated her BAC level was about 0.408, a potentially lethal concentration. She also submitted a copy of the final report from the rape kit she received three days after the event. Finally, Roe produced her then-boyfriend’s call logs from the night in question. It showed he called her 10 times that night but that she never answered, refuting Purdue’s claim that she was sober enough to answer and speak on the phone. Rollock addressed none of those points in her response to Roe’s appeal, which upheld the decision that Roe lied and and waived Roe’s rights to an investigation with the OSRR. Instead, Rollock deferred to Sermersheim to make the final decision on punishment. “Before you expelled (Roe),” Macey asked Sermersheim, “you did not look at the medical records she sent to Purdue?” “I suppose not,” Sermersheim replied, with a slight smile across her face. “Did you consult anyone on the effects that 18 drinks would have on someone (Roe’s) size?” he asked. “No,” she replied. Kealey countered that Roe had the opportunity to address these issues again after receiving the amended determination. The last line of the letter said Roe could further supplement her appeal by talking to Christina Wright, one of the lead investigators in Roe’s case. “The letter notified (you) of your opportunity to address whether you knowingly made false statements,” Kealey said. Kealey said it was irresponsible of Roe to make a report to Purdue without “looking into” what happened that night. Roe said she “blacked out” the night of the party, so she has few memories of it. Kealey displayed Facebook messages between Student B and Roe’s then-boyfriend on a screen, and he asked Roe to read portions of the messages aloud. The messages summarized what had happened that night between Student B and Roe: Roe, being extremely intoxicated, made sexual advances toward Student B and other members of the fraternity. When Student B went upstairs to his bedroom, Roe followed him and asked him to walk her home, which he did. While inside her residence hall, Roe asked Student B to wait in the women’s bathroom while she talked to her resident assistant and got a spare key for her room. Once inside the room, the two had sex. “Did you try to look into anything that we just read?” Kealey asked about whether she contacted any witnesses. “No,” Roe replied between sniffles. “I didn’t want to see anyone.” While she was dealing with the aftermath of Monday night’s party, Roe was still processing another sexual assault allegation, this one being against Ball State University, where she attended her freshman year. Was Nancy Roe ‘incapacitated’? “I remember blaming myself, and questioning why it happened more than once,” Roe said of her mindset after the alleged assault at Ball State. “I didn’t have any power in that situation, and I wanted to feel like I was in control of (this one).” Roe lost about $5,000 in tuition and fees when she was suspended from Purdue in October 2017. Too embarrassed to tell her family, she stayed in her Lafayette apartment until September of the following year, when she moved across the country to attend college on the west coast. She was denied by two Indiana schools, and an admissions counselor from one told her she would never get into a Midwestern college until her Purdue suspension ended. Originally on track to graduate in 2019, Roe’s college career was significantly delayed. She now plans to graduate at the end of this semester. After college, Roe wants to go to law school. “But with all this,” she said, “I’m not sure that’s gonna happen.” The plaintiff ended it’s testimonies with Rollock and expert witness Melinda Manning, resting it’s case Wednesday afternoon. Purdue’s counsel submitted a motion for judgement as matter of law following Wednesday’s conclusion. The motion asks the judge, rather than the jury, to make a verdict on the case, arguing that “a reasonable jury would not have a legally sufficient evidentiary basis to find (for the plaintiff).” The motion argues that the plaintiff hasn’t provided any evidence that can prove her claims of gender discrimination or lack of due process in her expulsion. The defendant’s witnesses, which include Student B, Wright and Roe’s R.A., to whom Roe reported the alleged assault, are expected to testify Thursday. Kealey said Tuesday he expects his case to rest Thursday evening, and closing arguments and the verdict will come Friday.


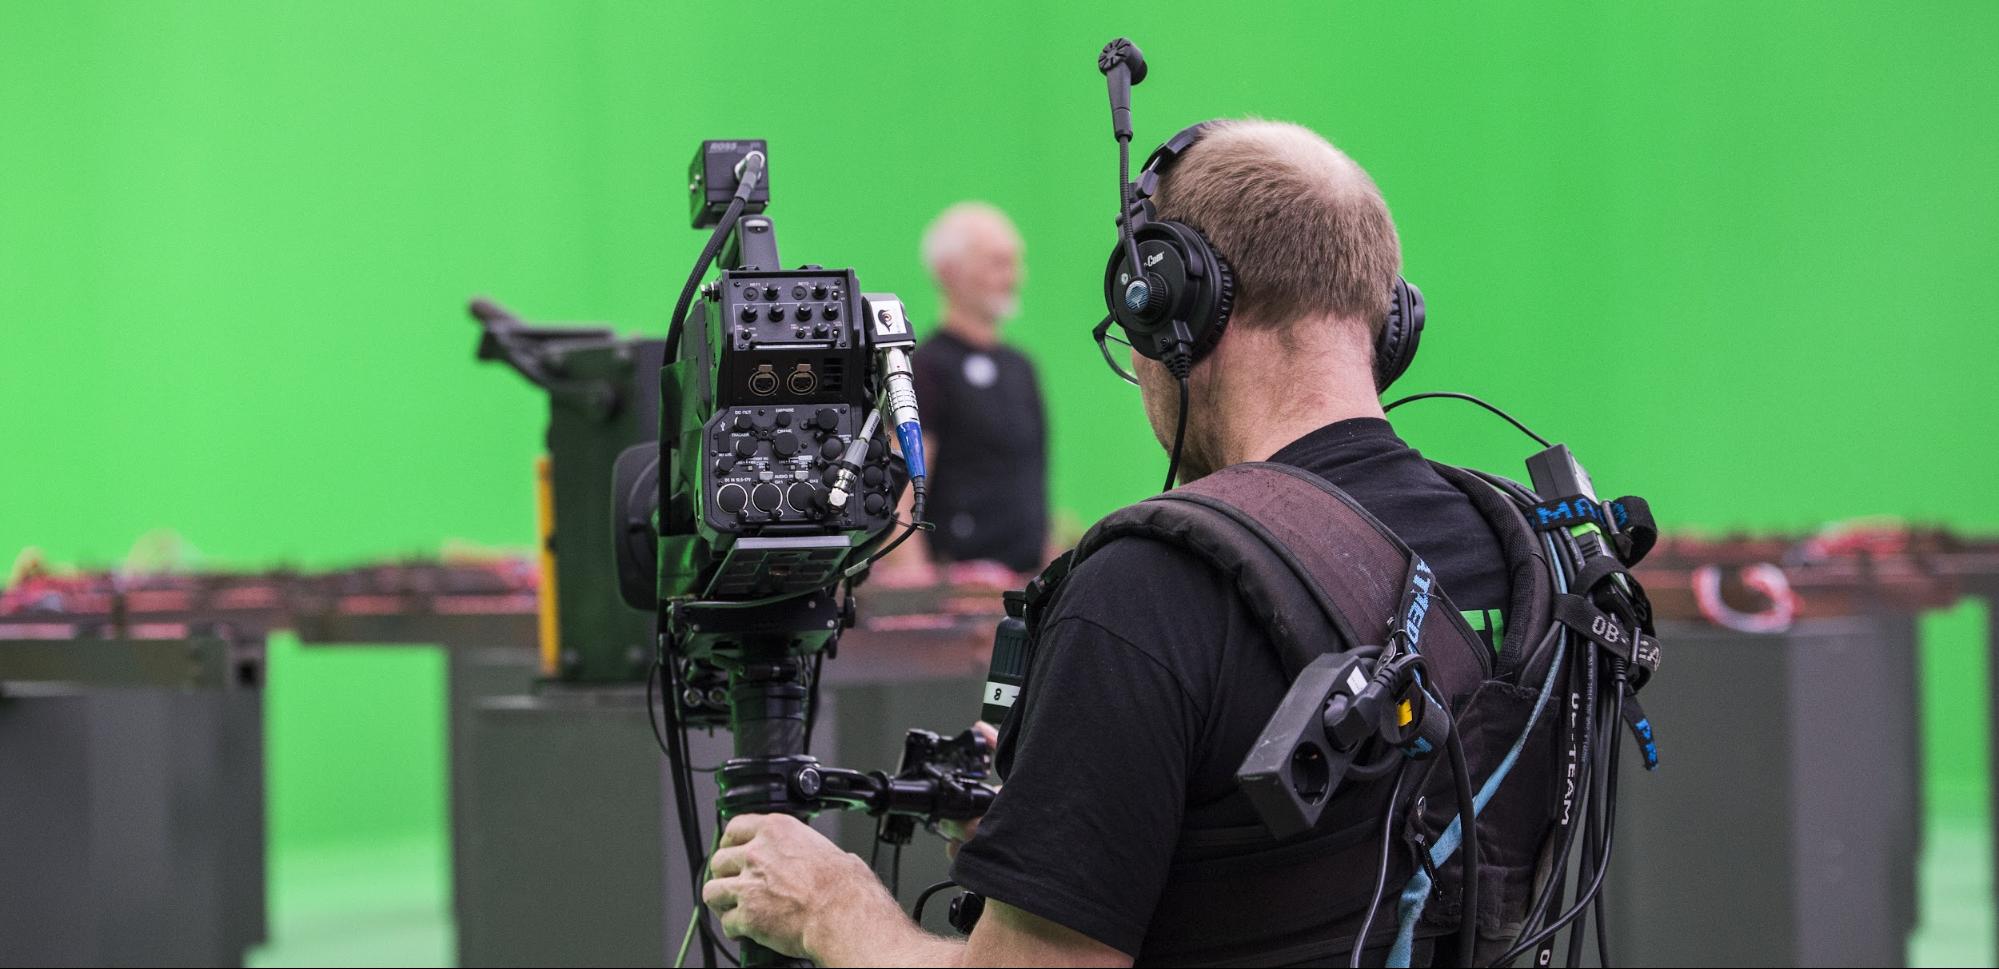
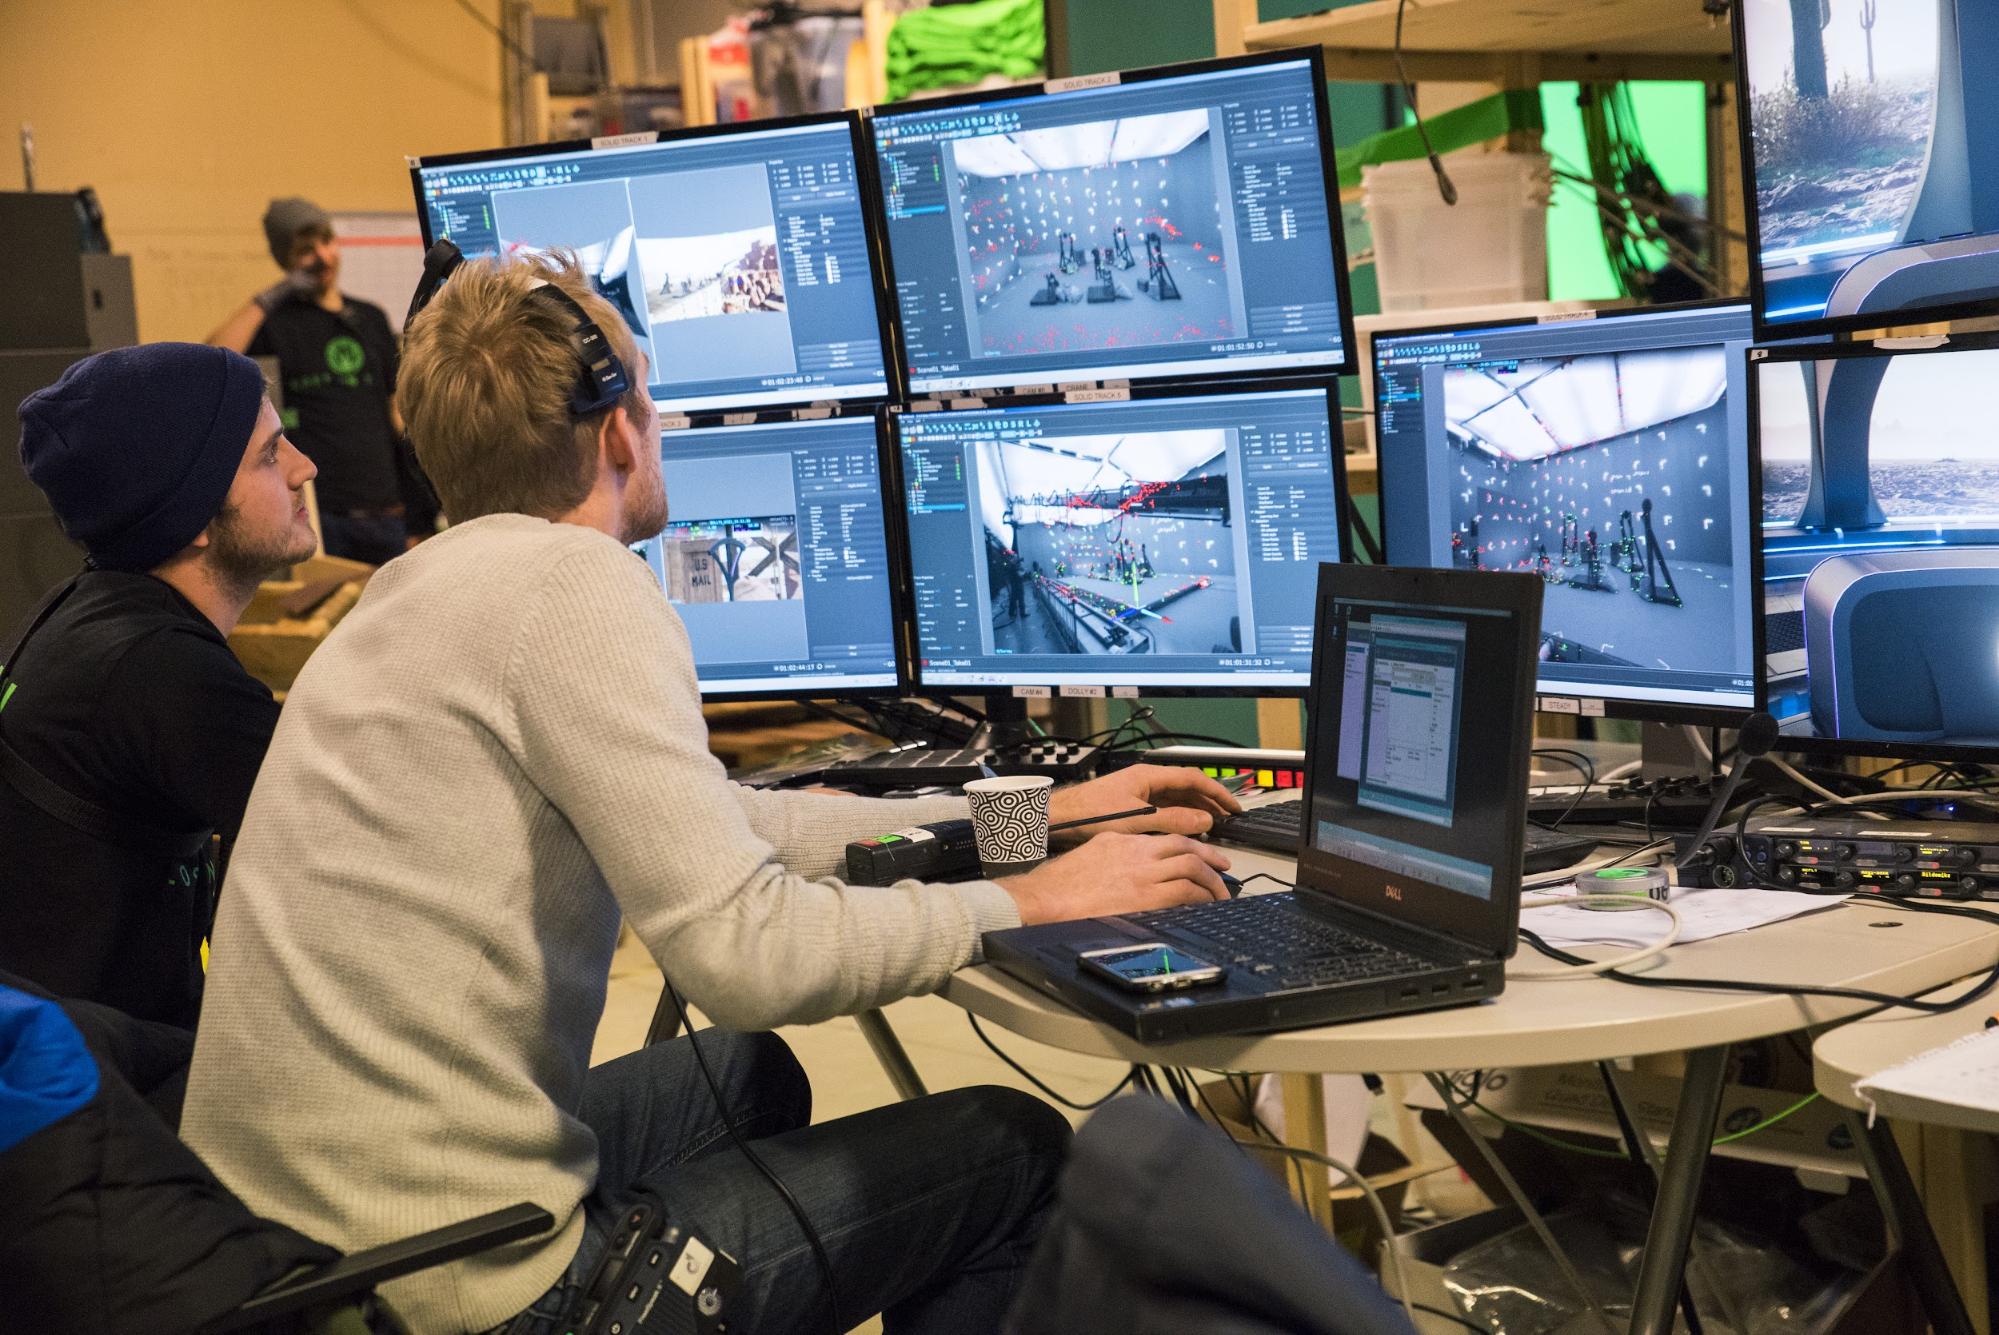


 Randy


